HandChestnut Robotics (formerly TetherIA)2025US
Aero Hand Open
Open-source tendon-driven five-finger hand with 7 actuated DOF (16 joints), fully 3D printed, weighing 389 g, with a Python SDK and ROS2 support.
Difficulty index
5.5/13| Class | hand | +3 |
|---|---|---|
| Cost | $324 BOM | +0.5 |
| DOF | 7 DOF | +0.7 |
| Parts | 194 parts | +1.3 |
Specimen photographs
6 items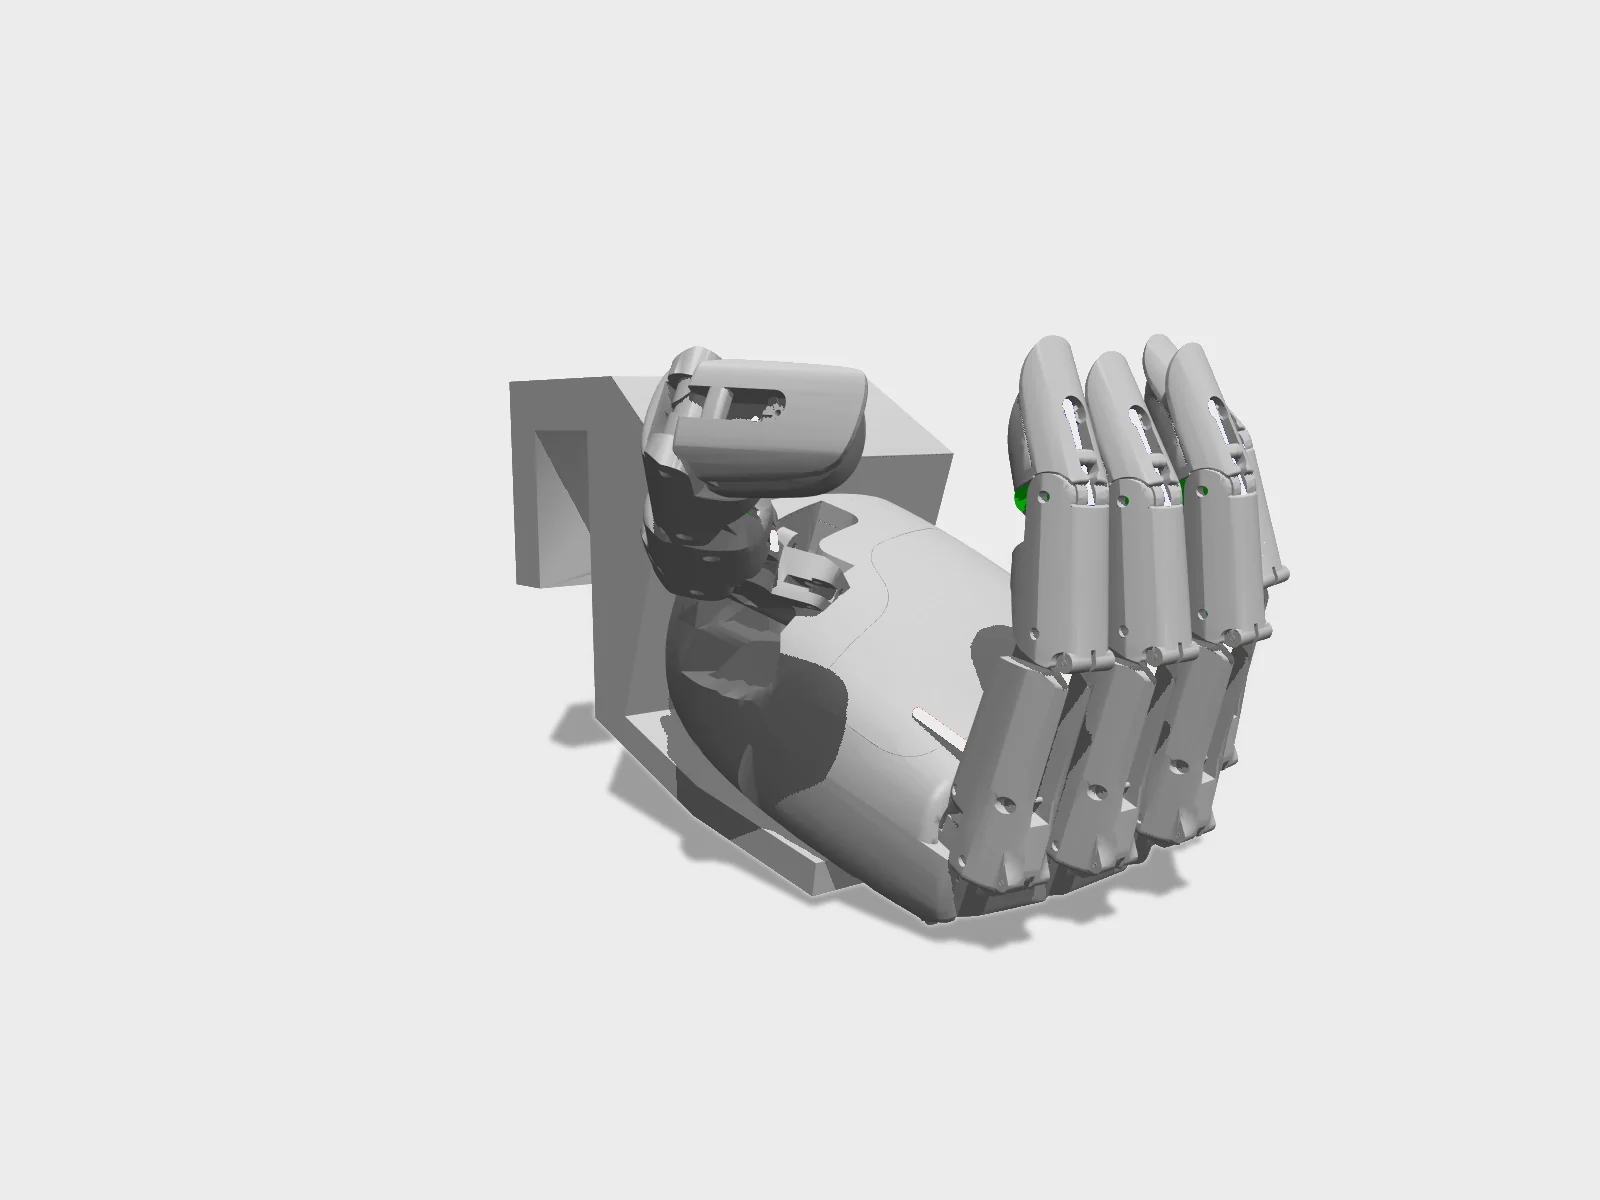
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/tetheria_aero_hand_open (Apache-2.0) · Hyperspawn render · source 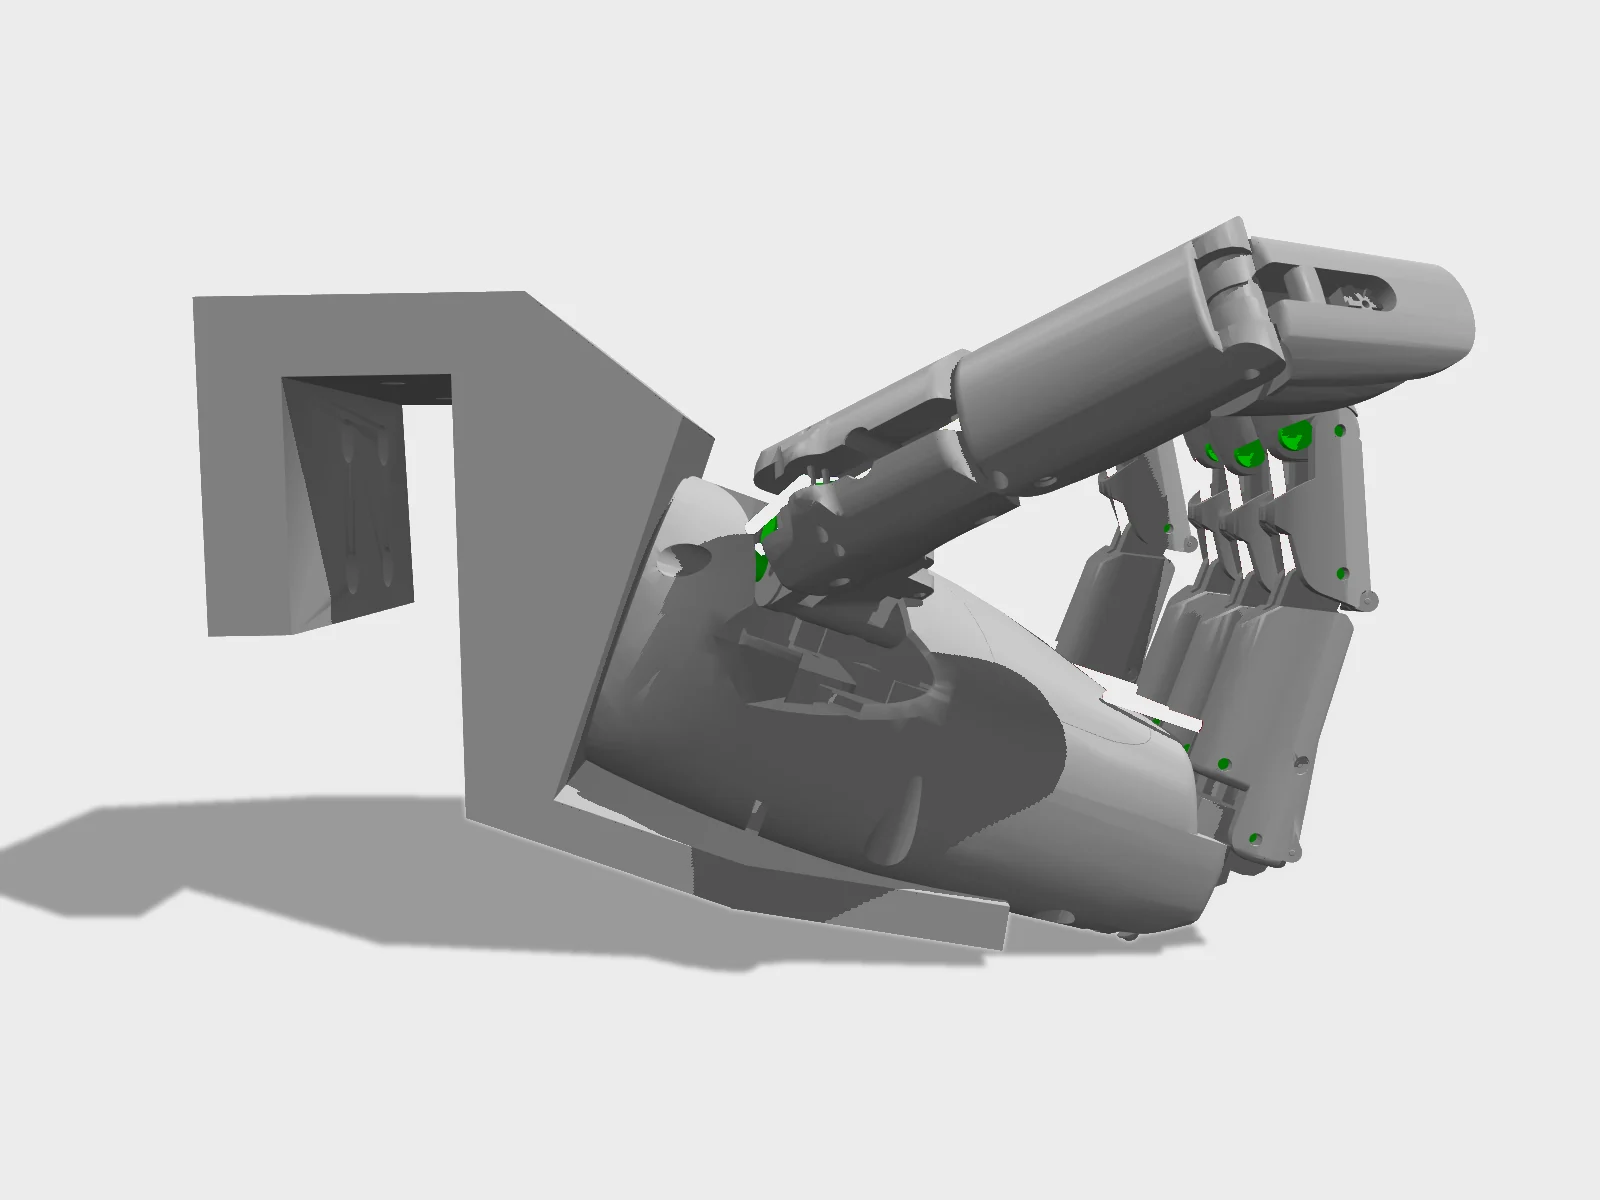
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/tetheria_aero_hand_open (Apache-2.0) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/tetheria_aero_hand_open (Apache-2.0) · Hyperspawn render · source 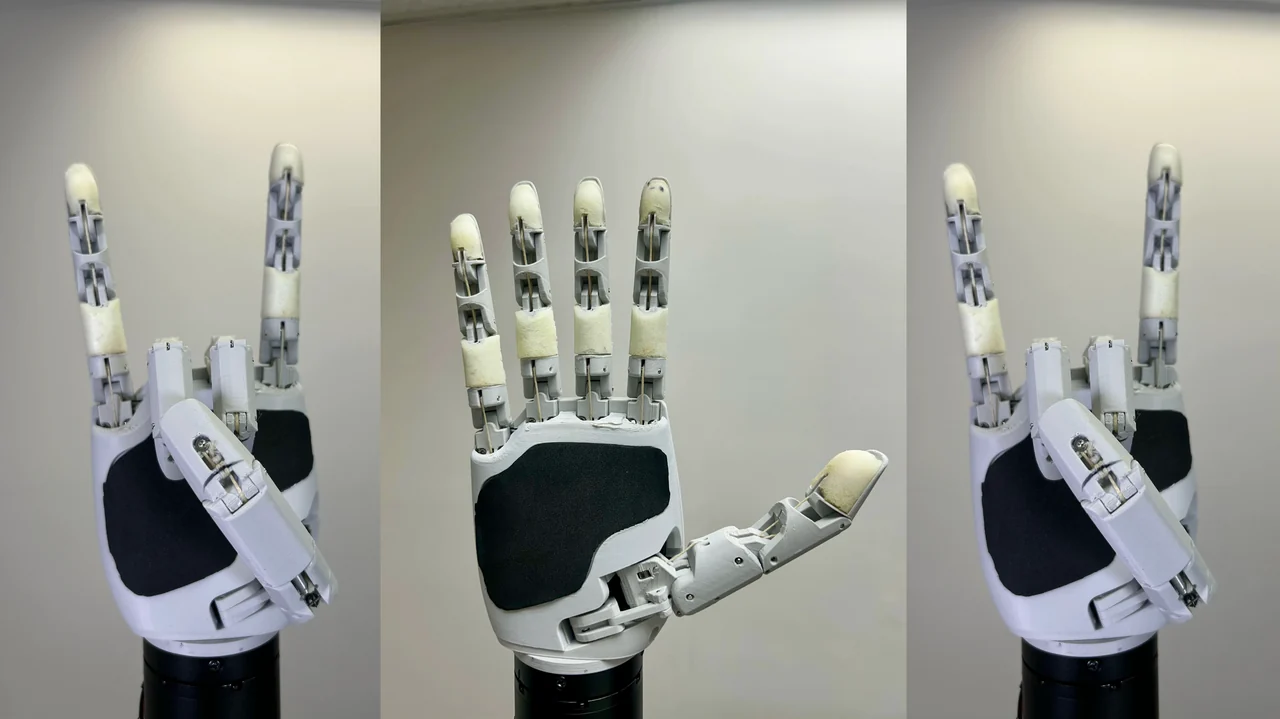
Banner from the aero-hand-open repo.Chestnut Robotics (aero-hand-open) · CC-BY-NC-SA-4.0 · source Introducing Aero Hand Open | TetherIA’s First Open-Source Robotic HandChestnutRobotics · official video, embedded · source Aero Hand Open Lifts a 5-Gallon Water Jug | Open-Source Robotic Hand Strength Test #roboticsChestnutRobotics · official video, embedded · source

Spec card
5/13 known- Degrees of freedom
- 7
- Mass
- 0.389 kg
- Price
- $314 · Complete kit $314
- BOM total
- $324 · 20/24 lines priced
- Part count
- 194
Not in the registry: height, payload, speed, runtime, battery, actuators, compute, sensors. Left blank rather than guessed.
What you learn building it
- +Tendon and linkage transmissions
- +Controlling many coupled joints
- +Tactile and proprioceptive sensing
- +Cable routing in tight spaces
- +FDM 3D printing: 38 parts
- +Tools used: FDM printer, bed >= 200 x 200 mm, Flush cutters, Files / sandpaper, Jewelry hand drill, 1.0 mm, 2.0 mm and 2.1 mm drill bits, Scissors / razor blade, Tape measure, Needle-nose pliers +22
- +23 assembly steps across 10 subassemblies
- +Flashing firmware for Seeed XIAO ESP32S3 (hand controller, 16-byte binary serial protocol, default 921600 baud), Feetech HLS3606M bus servos, IDs 0-6
- +Testing in simulation (URDF/MJCF) before touching hardware
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- not publicPolicies
Score 90/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: CC-BY-NC-SA-4.0. Software license: Apache-2.0.
Repos & models
Build it
Has an ORP build package.- BOM total
- $324
- Lines priced
- 20/24
- Parts
- 194
- Steps
- 23
- Version
- 0.1.0
4 lines have no price yet, so the real total is higher.
Largest BOM lines
| Part | Qty | Unit |
|---|---|---|
| Feetech HLS3606M 6 V smart servo (with mount plate, M2.3x5 spline screw, M2x4 plate screws and connection cable)HLS3606M | 7 | $29.83 |
| Finger distal/medial and thumb proximal/distal return spring (PIP), music wirePE020-140-33500-MW-0840-MH-N-IN | 5 | $5.27 |
| SparkFun snappable protoboard (optional control board / busbar) | 1 | $13.5 |
| Finger proximal/MCP return spring (MP), music wireM-35CS | 4 | $3.27 |
| 2x5x2.5 mm miniature bearing (MR52ZZ)MR52ZZ | 23 | $0.522 |
| M2 x 6 flanged Torx self-tapping screw96817A406 | 25 | $0.403 |
| Seeed Studio XIAO ESP32S3 (hand controller)XIAO ESP32S3 | 1 | $7.99 |
| Braided Vectran (or Kevlar) cord, spool: 11 tendons of 300 mm (4 finger pull incl. pinky, 4 finger coupling, thumb CMC flex, thumb pull, thumb coupling) | 1 | $6.29 |
- BOM total is $316.48 per hand in USD as stated in BOM.csv (printed parts and silicone are costed by volume, so real filament and silicone purchases cost more). The README quotes a $314 kit.
- The 6 V servo power supply and XT30 connector appear in the assembly guide but not in BOM.csv; no model or vendor is given. Size it for about 10 A peak per the firmware README.
- Design files (CAD, STL, BOM, docs) are CC BY-NC-SA 4.0, non-commercial; commercial manufacturing needs a licence from Chestnut Robotics. Firmware and SDK are Apache-2.0.
- Several BOM links were long search URLs; tracking parameters are stripped here. MISUMI undersized-pin links point at a series page where you select the size.
- Cable lengths per servo come from a table in the guide that is partly hard to read; only servo 1 (90 mm) and servos 3-5 (140 mm) are stated unambiguously. Check the guide page 10 for servos 2 and 6.
- The BOM row labels and the guide's part numbers differ (e.g. undersized 2x10 is P/N 37 in the BOM and 32 in the guide).
- The RL deployment README calls the GUI `aero-hand-gui`; the SDK installs `aero-open-gui`. The README also says `--select-packages`; colcon's flag is `--packages-select`.
- The BOM lists one undersized 2x20 pin that the guide never calls out by name; this package puts it with the thumb CMC pins. Check the Onshape model.
- The RL policy was validated only with the archived v0.1.0 firmware, not the newer binaries.
- Upstream disclaimer: research prototype, not validated for prolonged or heavy-duty use; tendons need periodic re-tensioning.
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
Bittle / Bittle X →Petoi · quadruped · index 7.5Easiest buildable quadruped, the next class up from hand. Adds gait generation.
NoteTetherIA rebranded to Chestnut Robotics (GitHub org renamed TetherIA -> Chestnut-Robotics). Design files are non-commercial; commercial manufacturing needs a license.
Sources
- [1]Aero Hand Open repo (specs, license TL;DR)checked 2026-09-24
- [2]Rebrand announcementchecked 2026-09-24
- [3]arXiv paperchecked 2026-09-24