HumanoidDuke University General Robotics Lab2024US
Duke Humanoid v1
Open-source 10-DOF research biped for energy-efficient RL locomotion exploiting passive dynamics.
Difficulty index
9.3/13| Class | humanoid | +5 |
|---|---|---|
| Cost | unknown · midpoint | +1.5 |
| DOF | 10 DOF | +1 |
| Parts | 602 parts | +1.8 |
Top of the ladder. This robot lives on the humanoid domains.
Specimen photographs
2 items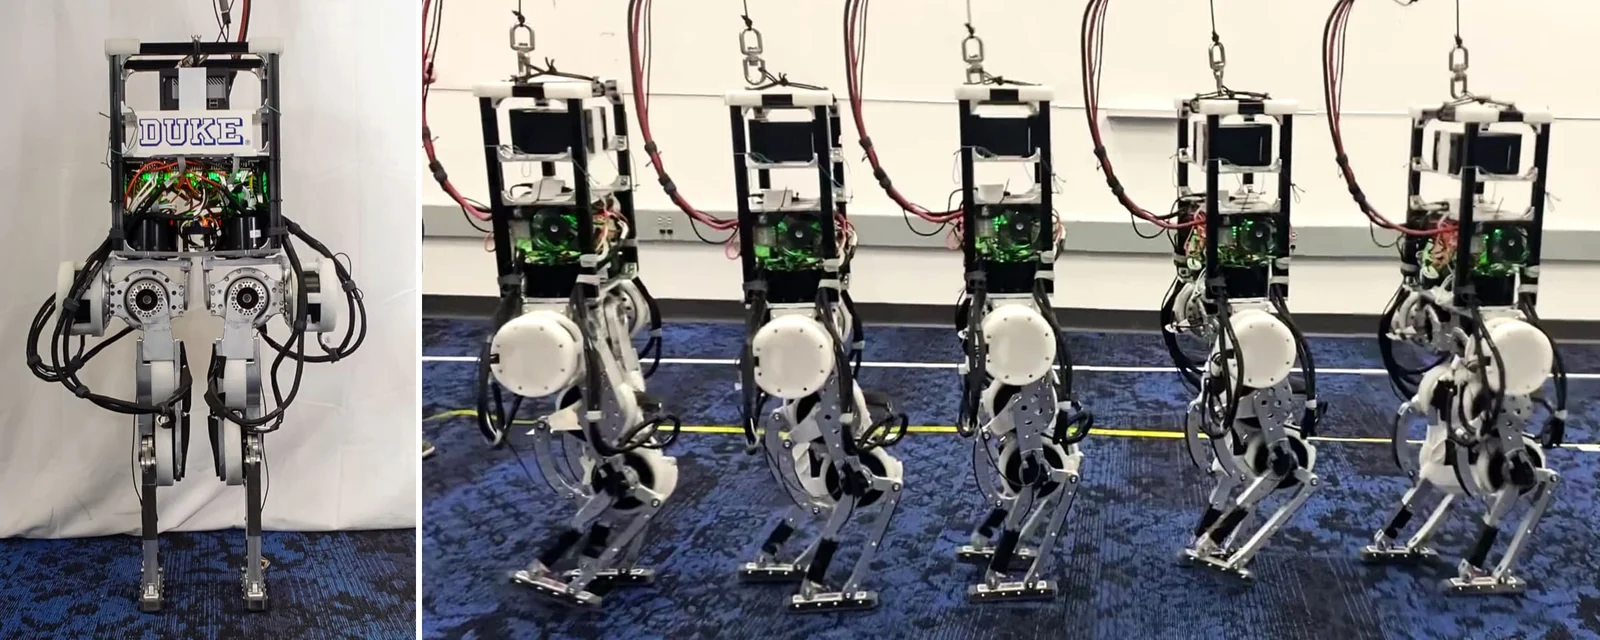

Spec card
3/13 known- Degrees of freedom
- 10
- Price
- not for sale
- Part count
- 602
Not in the registry: height, mass, payload, speed, runtime, battery, bom total, actuators, compute, sensors. Left blank rather than guessed.
What you learn building it
- +Whole-body control
- +Dozens of actuators on one bus
- +Balance and fall handling
- +Safe bring-up of a full-size machine
- +CNC machining: 65 parts
- +FDM 3D printing: 25 parts
- +Tools used: FDM printer (lab used Bambu Lab X1C and Prusa MK4), Smooth PEI (PLA) and textured PEI (TPU) sheets, Heat gun, Hex keys (wiki recommends Bondhus), Hex keys, Soldering iron, Multimeter, Crimp tool +7
- +18 assembly steps across 6 subassemblies
- +Flashing firmware for teensy_comm (Teensy 4.0 sensor hub), Elmo drive parameters (.gprm per joint pair), ethercat_motor_py (host EtherCAT master, SOEM)
- +Testing in simulation (URDF/MJCF) before touching hardware
- +Running published learned policies
Openness
- publicCAD
- publicBOM
- not publicFirmware
- publicSim model
- publicSoftware
- publicPolicies
Score 85/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Software license: MIT.
Repos & models
Build it
Has an ORP build package.Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
None. This is the top. Find people building it on humanoidrobots.team.
This is the top of the ladder.
NotePaper arXiv:2409.19795. Hardware wiki on Notion holds the BOM, CNC/DIY CAD zips and Fusion files; the GitHub repo holds code, URDF and policies. The repo is MIT; the Notion CAD has no stated license. v1 is legs only on a box body and tethered (48 V bench supplies, external Linux PC over EtherCAT); motors and drives are quote-only from Motorevo. Repo inactive since Jun 2025; the lab published Duke Humanoid V2 repos in Aug-Sep 2026 (generalroboticslab/duke_humanoid_v2).
Sources
- [1]Official repochecked 2026-09-24
- [2]arXiv paperchecked 2026-09-24
- [3]Duke Humanoid V1 hardware wiki (Notion: BOM, CAD, power, EtherCAT)checked 2026-09-25
- [4]duke_humanoid_v2 repo (created 2026-08-25)checked 2026-09-25