HumanoidFourier (Fourier Intelligence)2025CN
Fourier N1
1.3 m, 38 kg humanoid launched April 2025 with open-released BOM, design drawings, assembly guides and base software.
Difficulty index
9.9/13| Class | humanoid | +5 |
|---|---|---|
| Cost | unknown · midpoint | +1.5 |
| DOF | 23 DOF | +2.3 |
| Parts | 133 parts | +1.1 |
Top of the ladder. This robot lives on the humanoid domains.
Specimen photographs
4 items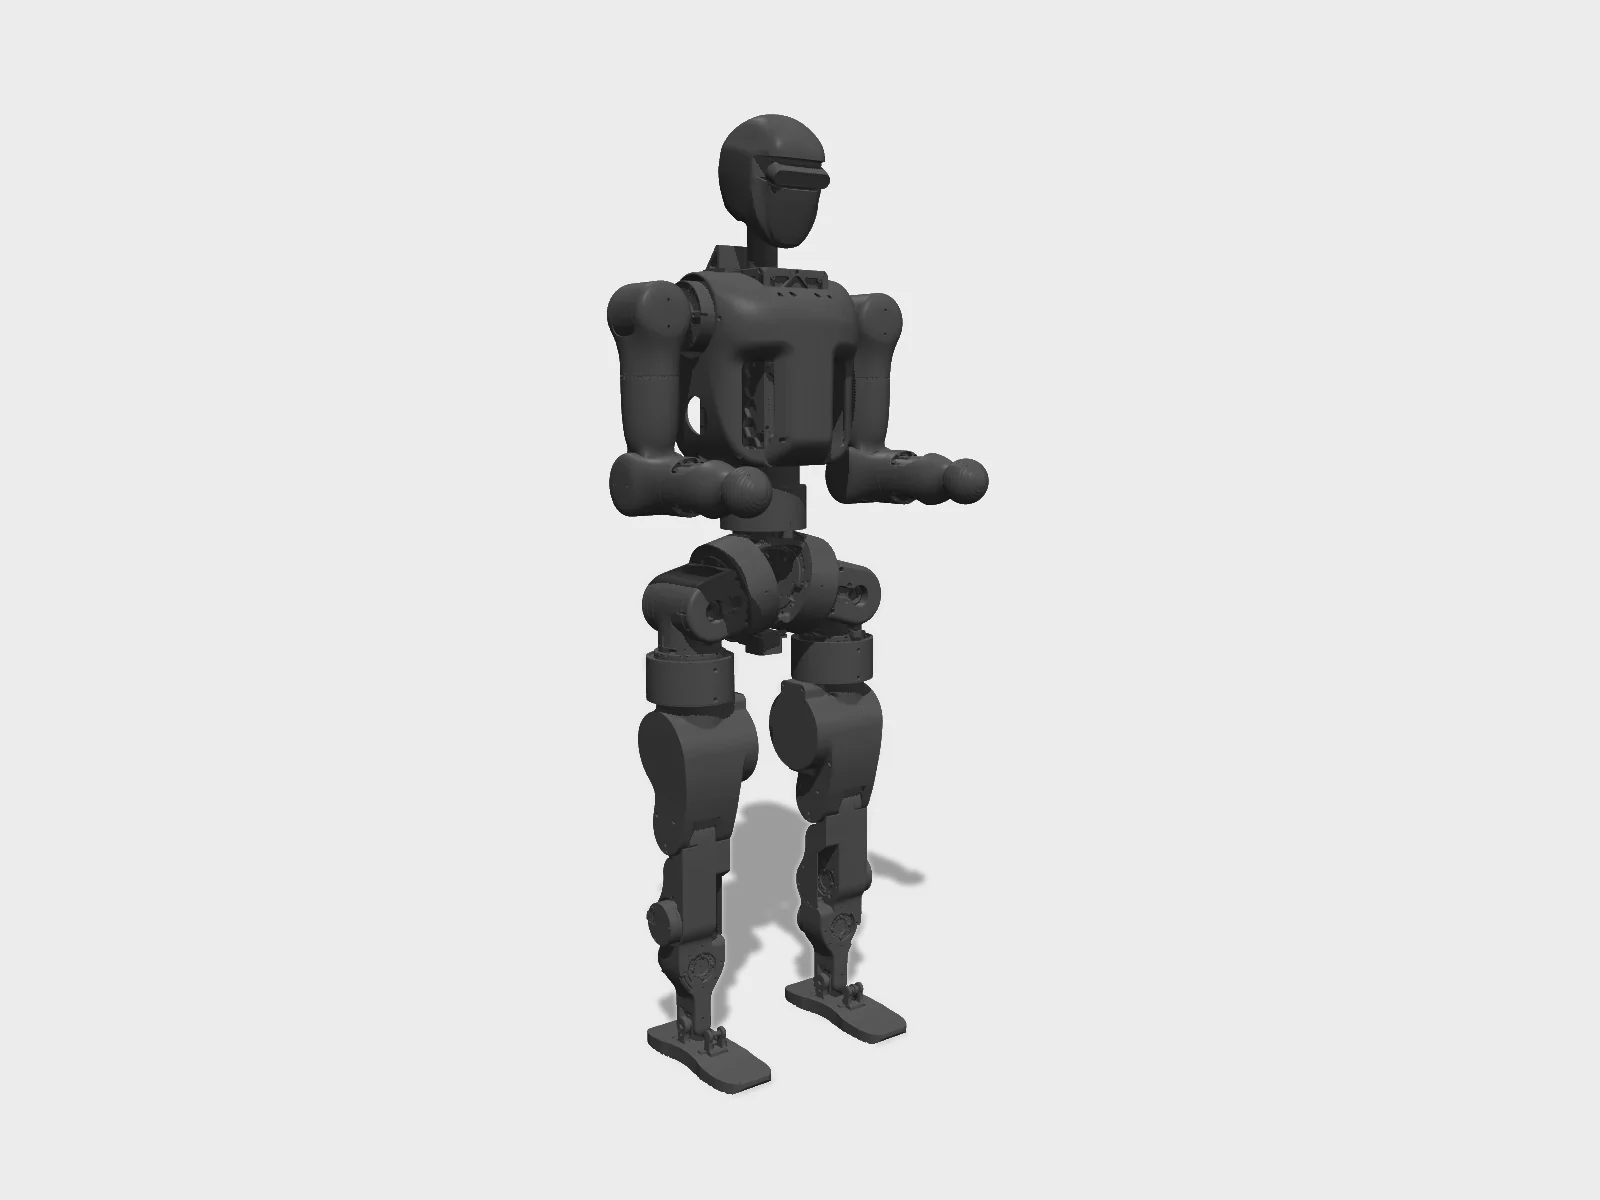
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/fourier_n1 (Apache-2.0) · Hyperspawn render · source 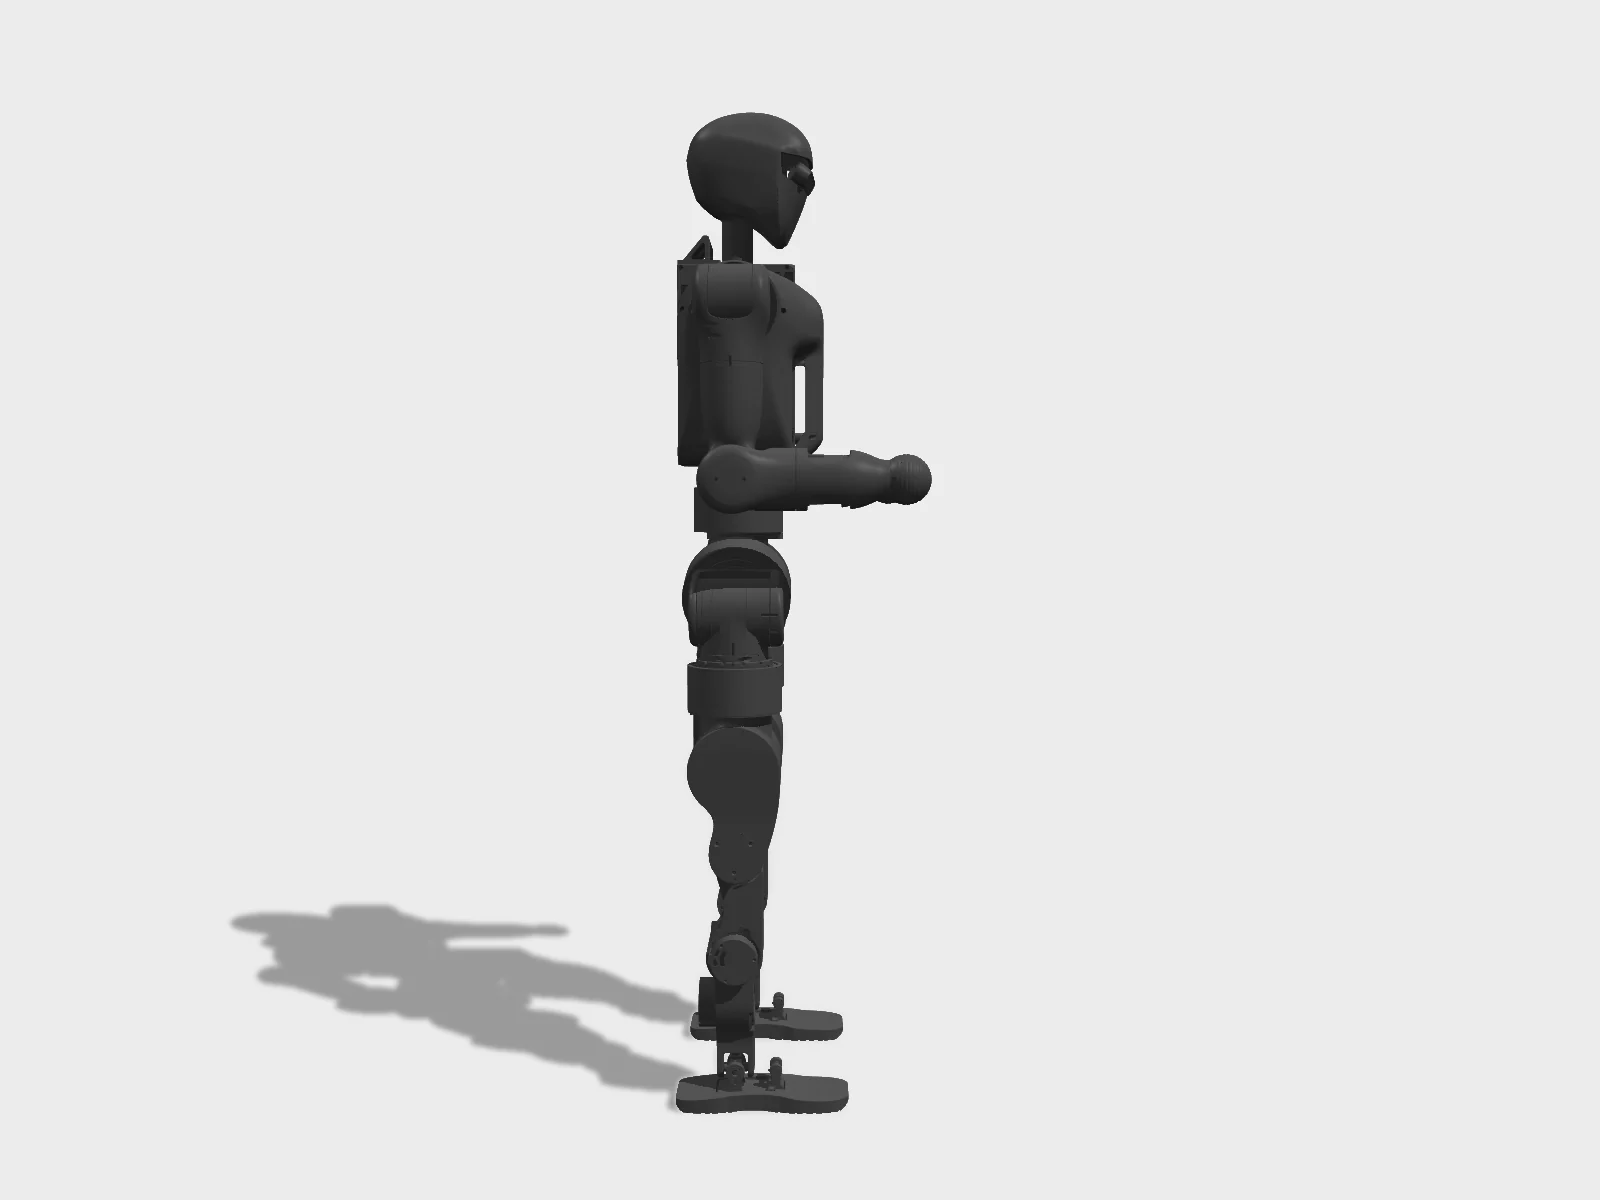
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/fourier_n1 (Apache-2.0) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/fourier_n1 (Apache-2.0) · Hyperspawn render · source Fourier N1 | Street Dance BotFourier · official video, embedded · source
Spec card
7/13 known- Degrees of freedom
- 23
- Height
- 130 cm
- Mass
- 38 kg
- Speed
- 3.5 m/s
- Runtime
- 120 min
- Part count
- 133
- Actuators
- Fourier FSA actuators; URDF effort limits 95 N·m x4, 54 N·m x7, 30 N·m x12
Not in the registry: payload, battery, price, bom total, compute, sensors. Left blank rather than guessed.
What you learn building it
- +Whole-body control
- +Dozens of actuators on one bus
- +Balance and fall handling
- +Safe bring-up of a full-size machine
- +CNC machining: 100 parts
- +12 assembly steps across 11 subassemblies
- +Flashing firmware for Main computer: fourier-grx (.deb, Ubuntu 22.04 x86-64, Python 3.11; closed binary run.bin, no license), Fourier FSA actuators x23 (FSA v2 protocol over Ethernet, 48 V; actuator firmware not published), USB IMU (serial, 500 Hz)
- +Testing in simulation (URDF/MJCF) before touching hardware
- +Running published learned policies
Openness
- publicCAD
- publicBOM
- not publicFirmware
- publicSim model
- publicSoftware
- publicPolicies
Score 85/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Software license: MIT.
Repos & models
Build it
Has an ORP build package.Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
None. This is the top. Find people building it on humanoidrobots.team.
This is the top of the ladder.
NoteThe 23 DOF count excludes hands. The open-source package is published as the docs repo FFTAI/fourier-grx-N1 (MIT); there is no FFTAI/N1 repo. Press (Yicai, TMTPost) called it the first open-source humanoid; that claim is disputed. The MIT license covers the docs repo; no license for the hardware files was found, so hw is left undeclared. The N1 URDF (Wiki-GRx-Models, FourierN1 branch) sets a 95 N·m max effort on the four strongest joints; launch press said 96 N·m peak. Walking policies (TorchScript policy_jit_walk.pt) ship in Wiki-GRx-Deploy (FourierN1 branch) with Isaac Gym training (Wiki-GRx-Gym) and MuJoCo sim2sim (Wiki-GRx-Mujoco). fourier-grx itself is a closed binary.
Sources
- [1]TMTPost: Fourier N1checked 2026-09-24
- [2]Humanoids Daily N1checked 2026-09-24
- [3]fourier-grx-N1 repochecked 2026-09-24
- [4]N1 URDF (effort limits 95/54/30 N·m)checked 2026-09-25
- [5]Wiki-GRx-Deploy FourierN1 branch (walking policies)checked 2026-09-25
- [6]fourier_actuator_sdkchecked 2026-09-25
- [7]Fourier N1 open-source launch pagechecked 2026-09-25
- [8]N1 hardware pack on Baidu Netdisk (download needs a Baidu login)checked 2026-09-25