HumanoidHyperspawn Robotics2023IN
Dropbear
Full-size open-source humanoid from Hyperspawn and Pointblank: FDM-printed structure on 20x20 aluminium extrusion, MyActuator CAN actuators, an ESP32 node per limb and a Jetson Orin brain. CAD, BOM, printables, firmware, URDF/MJCF/USD and simulation walking policies are public; a pre-assembled kit is on preorder.
Difficulty index
12.0/13| Class | humanoid | +5 |
|---|---|---|
| Cost | $9,948 BOM | +2 |
| DOF | 32 DOF | +3 |
| Parts | 1835 parts | +2 |
Top of the ladder. This robot lives on the humanoid domains.
Specimen photographs
17 itemsTurntable render of the current Dropbear build. Looping, muted, 5.3 s.Hyperspawn · Hyperspawn · source 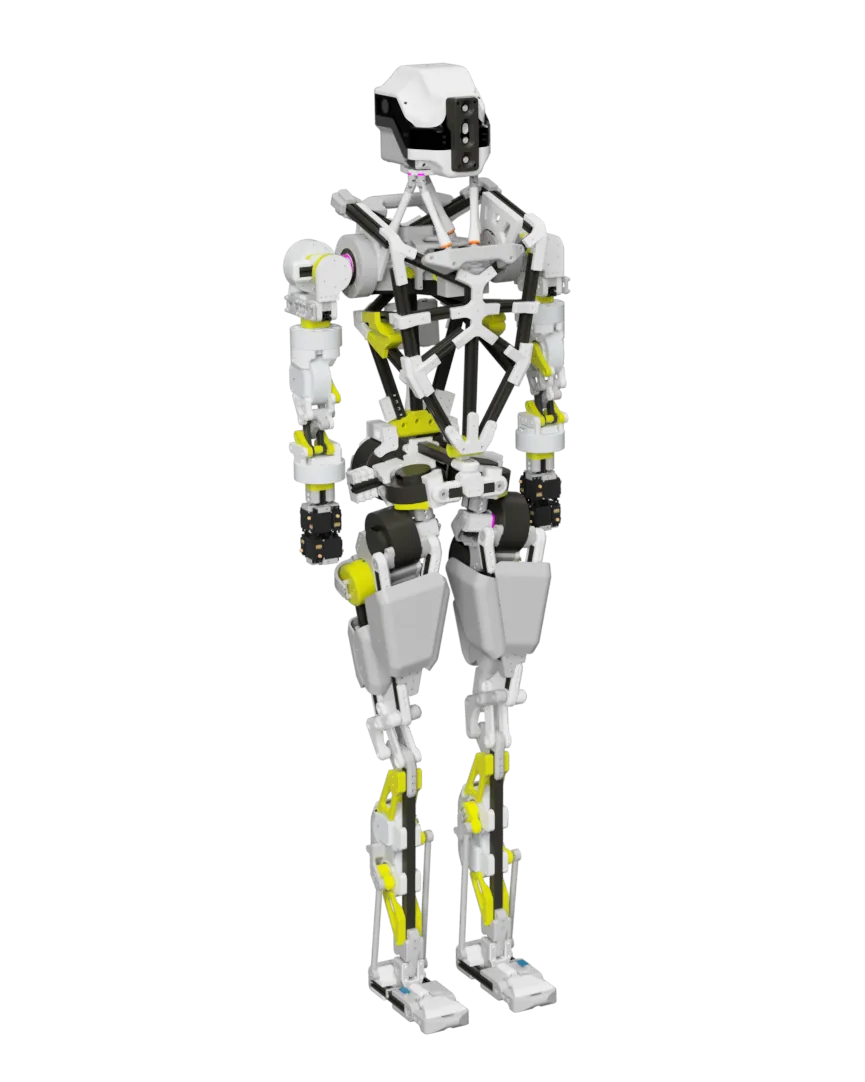
Full-assembly CAD render from dropbear_hardware.Hyperspawn · Hyperspawn · source Simulation, not hardware: 30 s Isaac Lab rollout of the experimental v0.2.0 policy (model_10479.pt) at 50 Hz.Hyperspawn; policy by Hyperspawn Robotics and robit-man (dropbear-locomotion) · CC-BY-NC-SA-4.0 · source 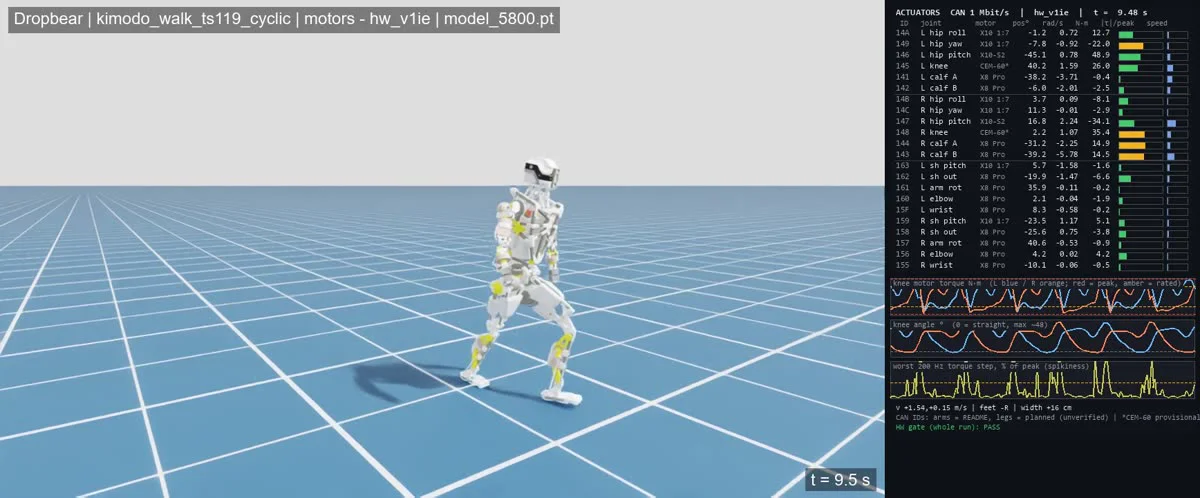
Simulation: deployable walk on the datasheet motor twin (no-state policy, 20 ms target ramp). Hardware gate PASS.Hyperspawn (dropbear-wbc) · PolyForm-Noncommercial-1.0.0 · source 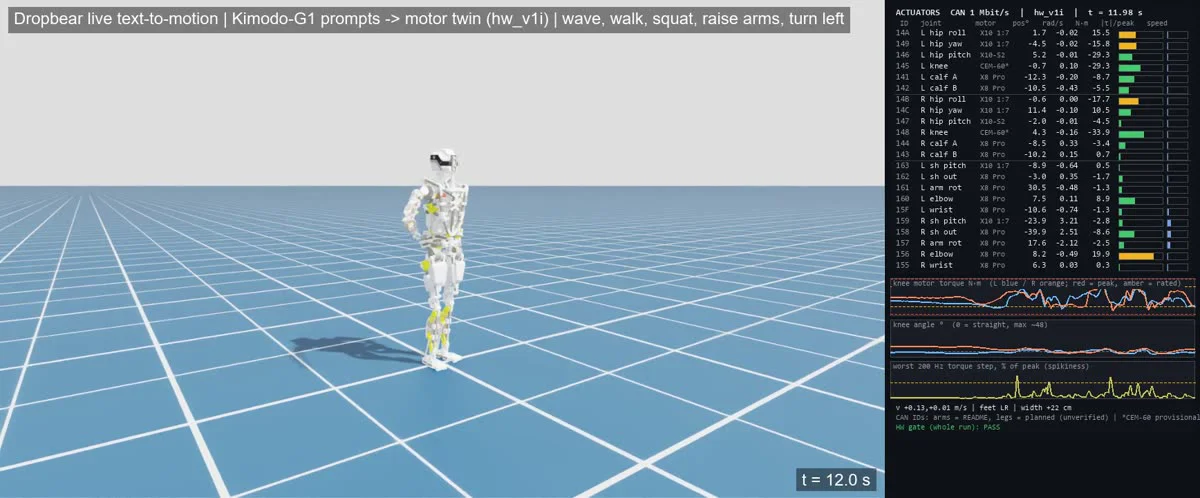
Simulation: live text to motion. A typed prompt, generated by Kimodo, played on the motor twin.Hyperspawn (dropbear-wbc) · PolyForm-Noncommercial-1.0.0 · source 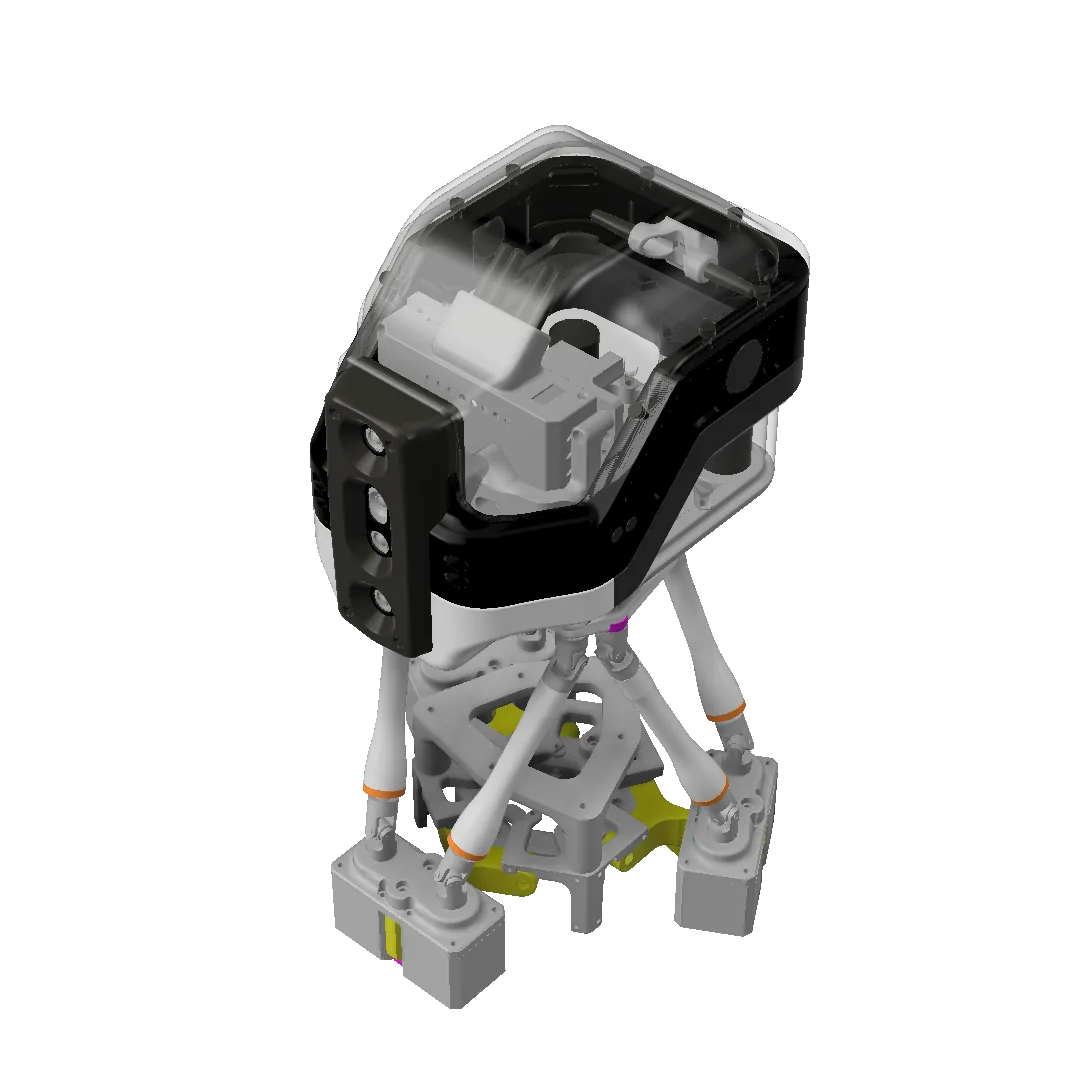
Head and Stewart-platform neck subassembly (six NEMA 17 lead-screw legs).Hyperspawn · Hyperspawn · source 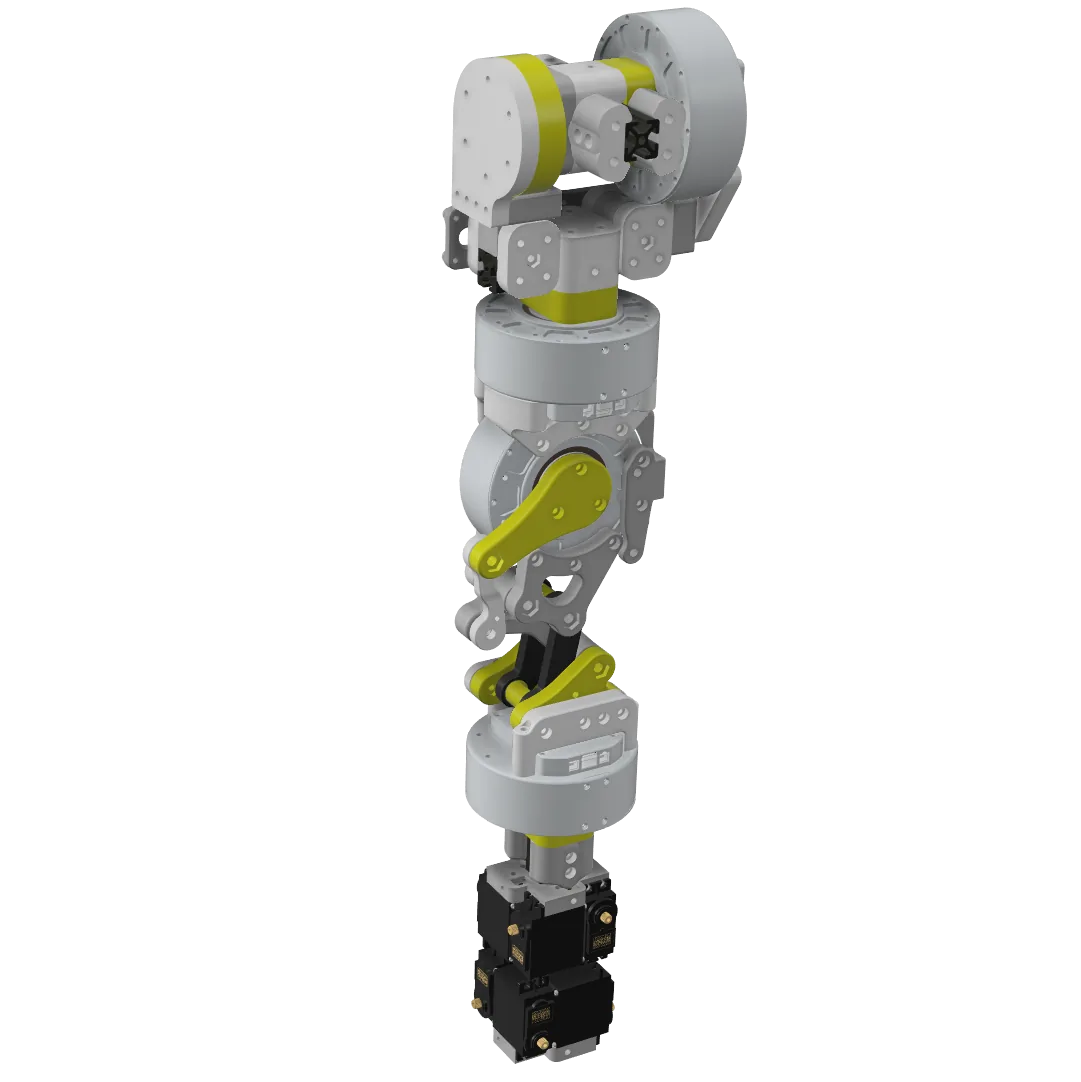
Right arm subassembly.Hyperspawn · Hyperspawn · source 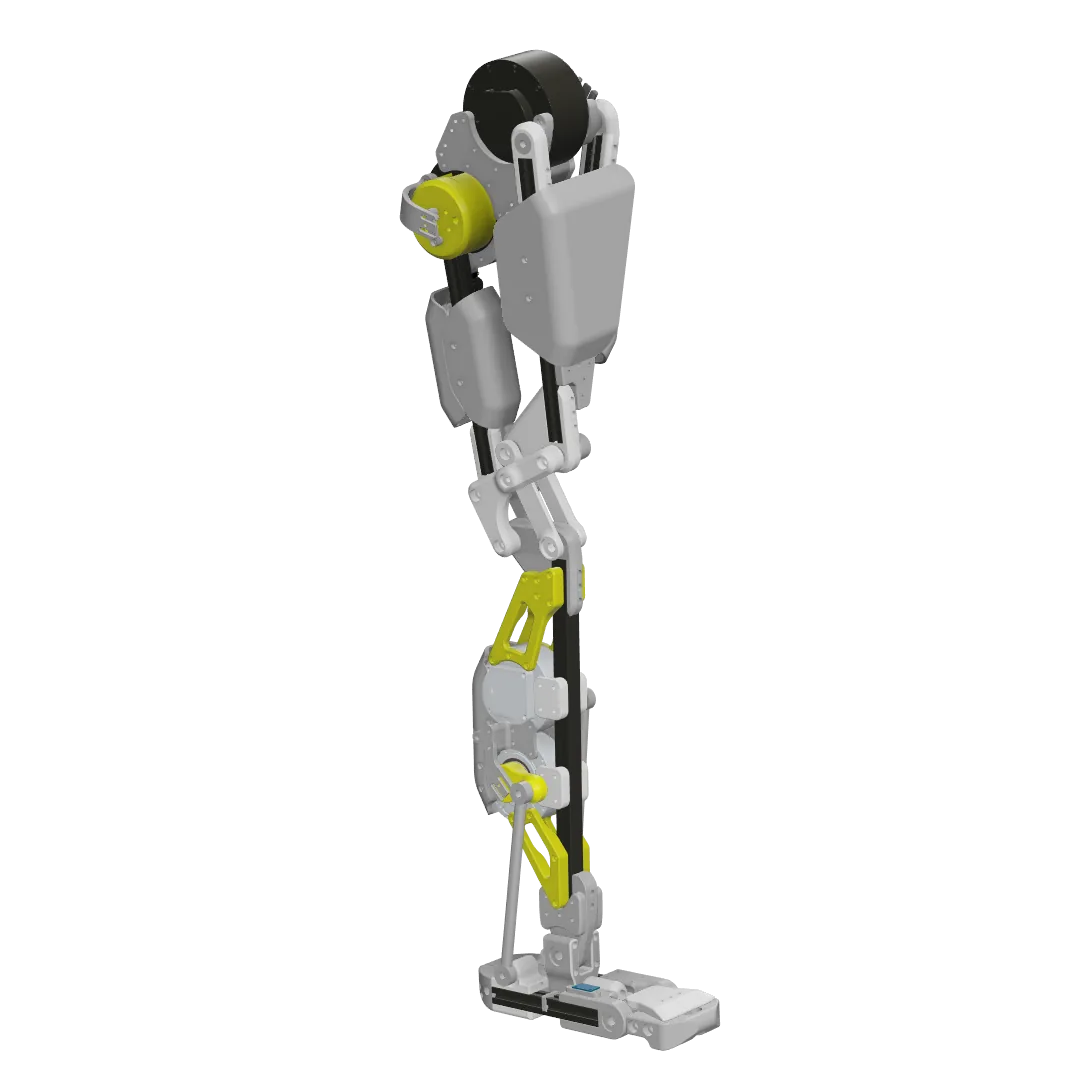
Right leg subassembly with the tie-rod ankle drive.Hyperspawn · Hyperspawn · source 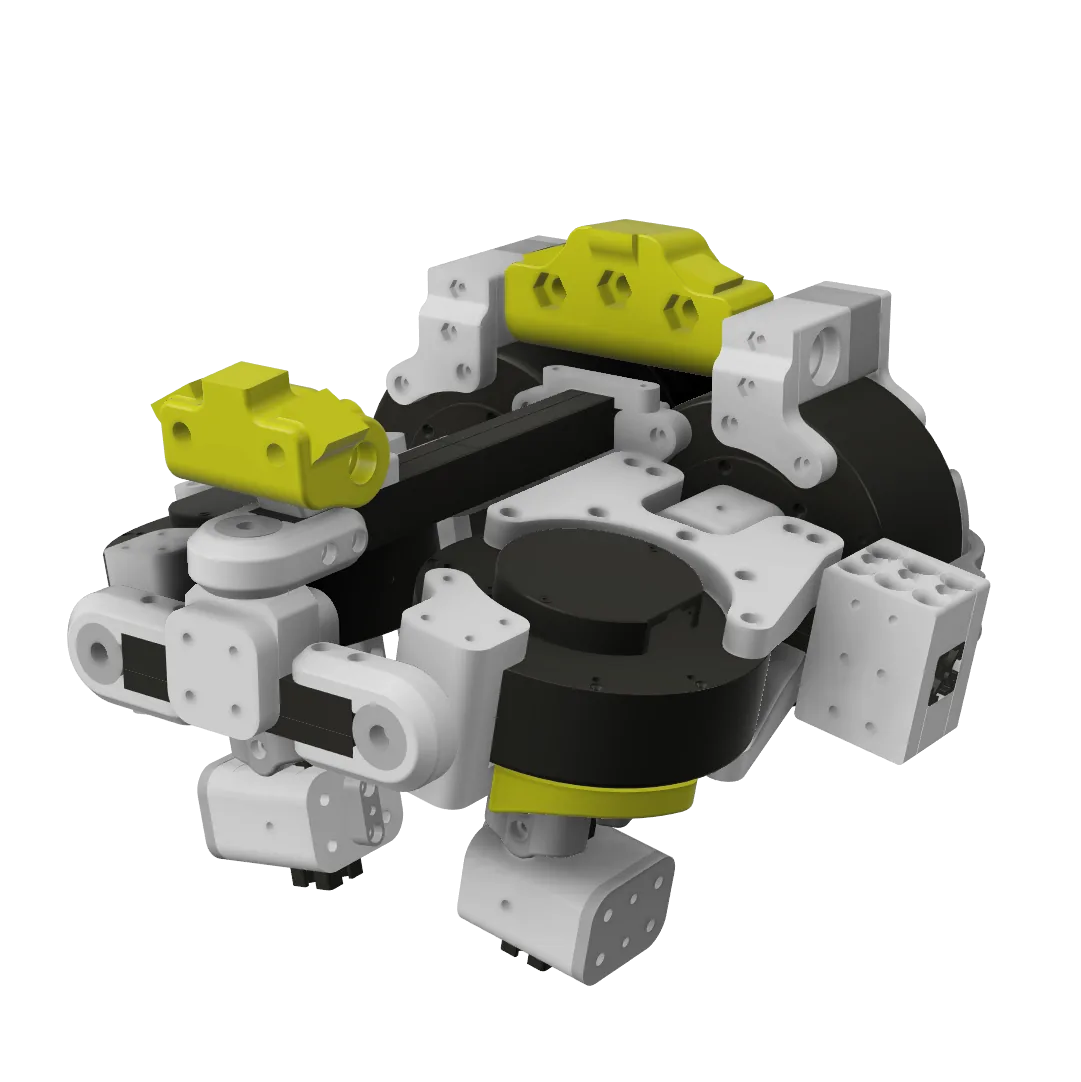
Pelvic girdle subassembly.Hyperspawn · Hyperspawn · source
Show 7 more
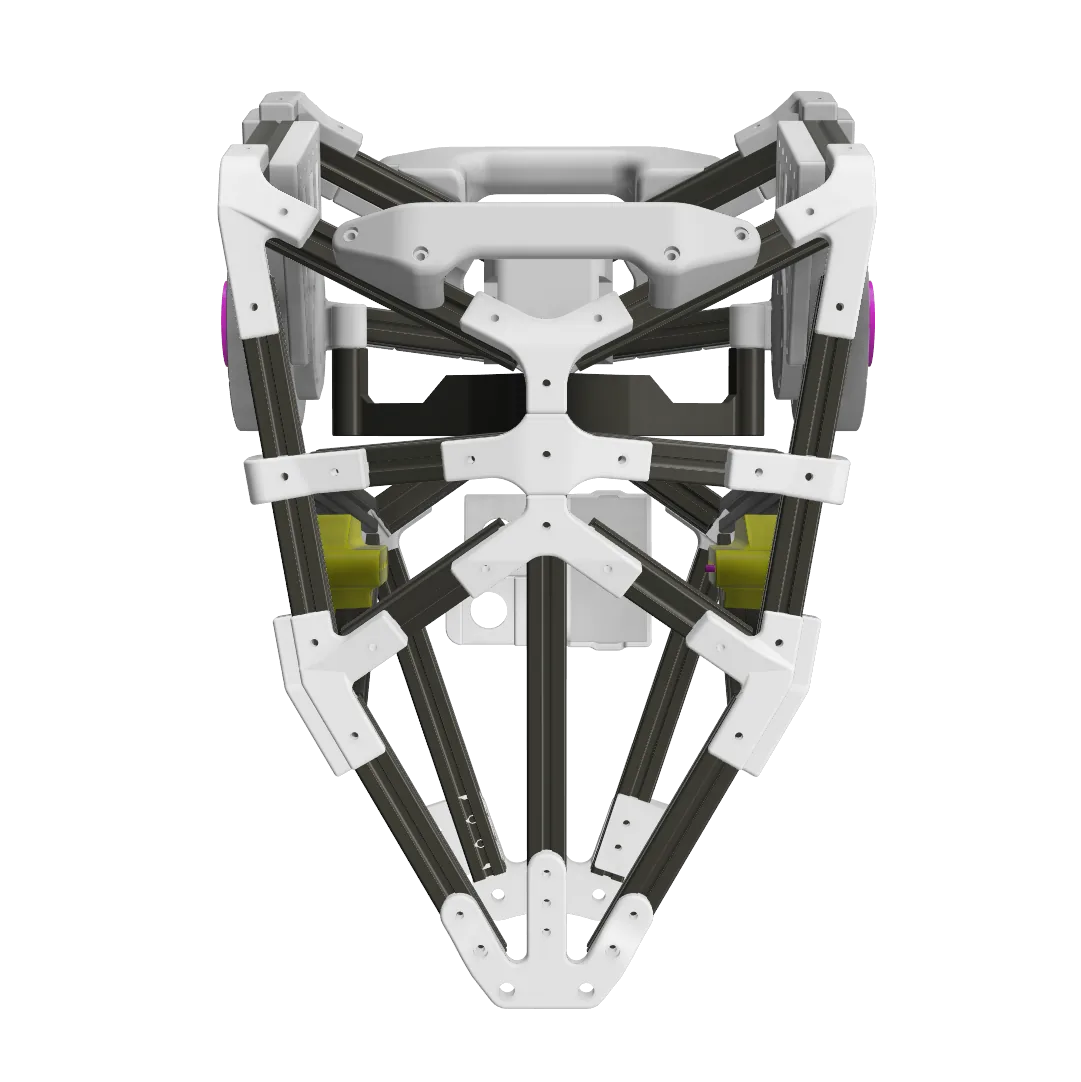
Torso subassembly: 20x20 extrusion cage and printed brackets.Hyperspawn · Hyperspawn · source Simulation: v0.1.0 policy, 0.20 m/s robot-left command, in the dropbear-locomotion live viewer.Hyperspawn Robotics and robit-man (dropbear-locomotion) · CC-BY-NC-SA-4.0 · source Simulation: v0.1.0 policy strafing, in the dropbear-locomotion live viewer.Hyperspawn Robotics and robit-man (dropbear-locomotion) · CC-BY-NC-SA-4.0 · source 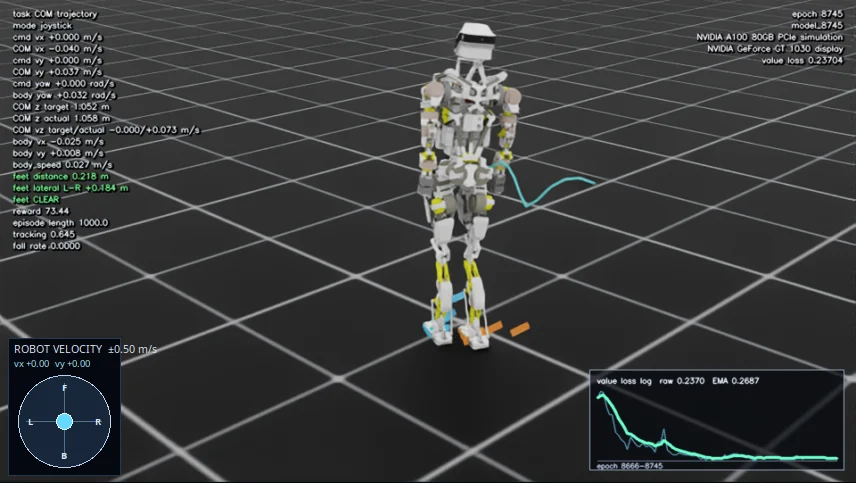
Simulation: joystick mode in the live viewer (model_8745), COM trajectory and foot targets drawn.Hyperspawn Robotics and robit-man (dropbear-locomotion) · CC-BY-NC-SA-4.0 · source 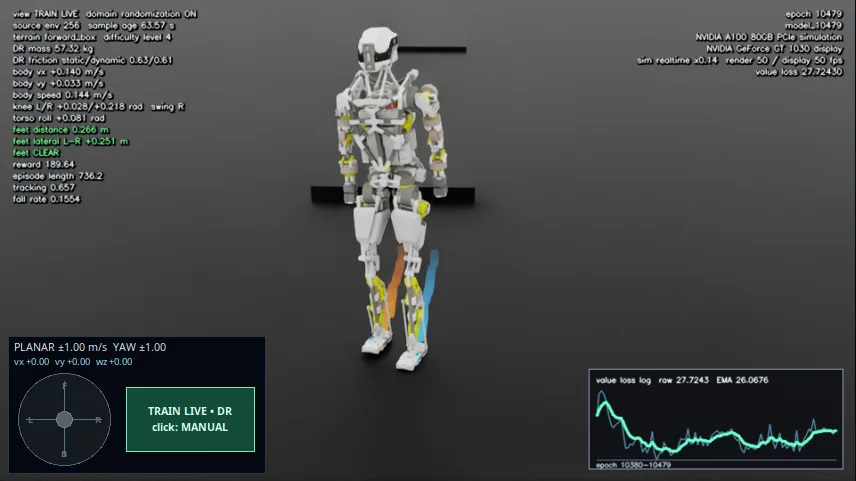
Live viewer mirroring an Isaac Lab training environment (randomised mass and friction).Hyperspawn Robotics and robit-man (dropbear-locomotion) · CC-BY-NC-SA-4.0 · source 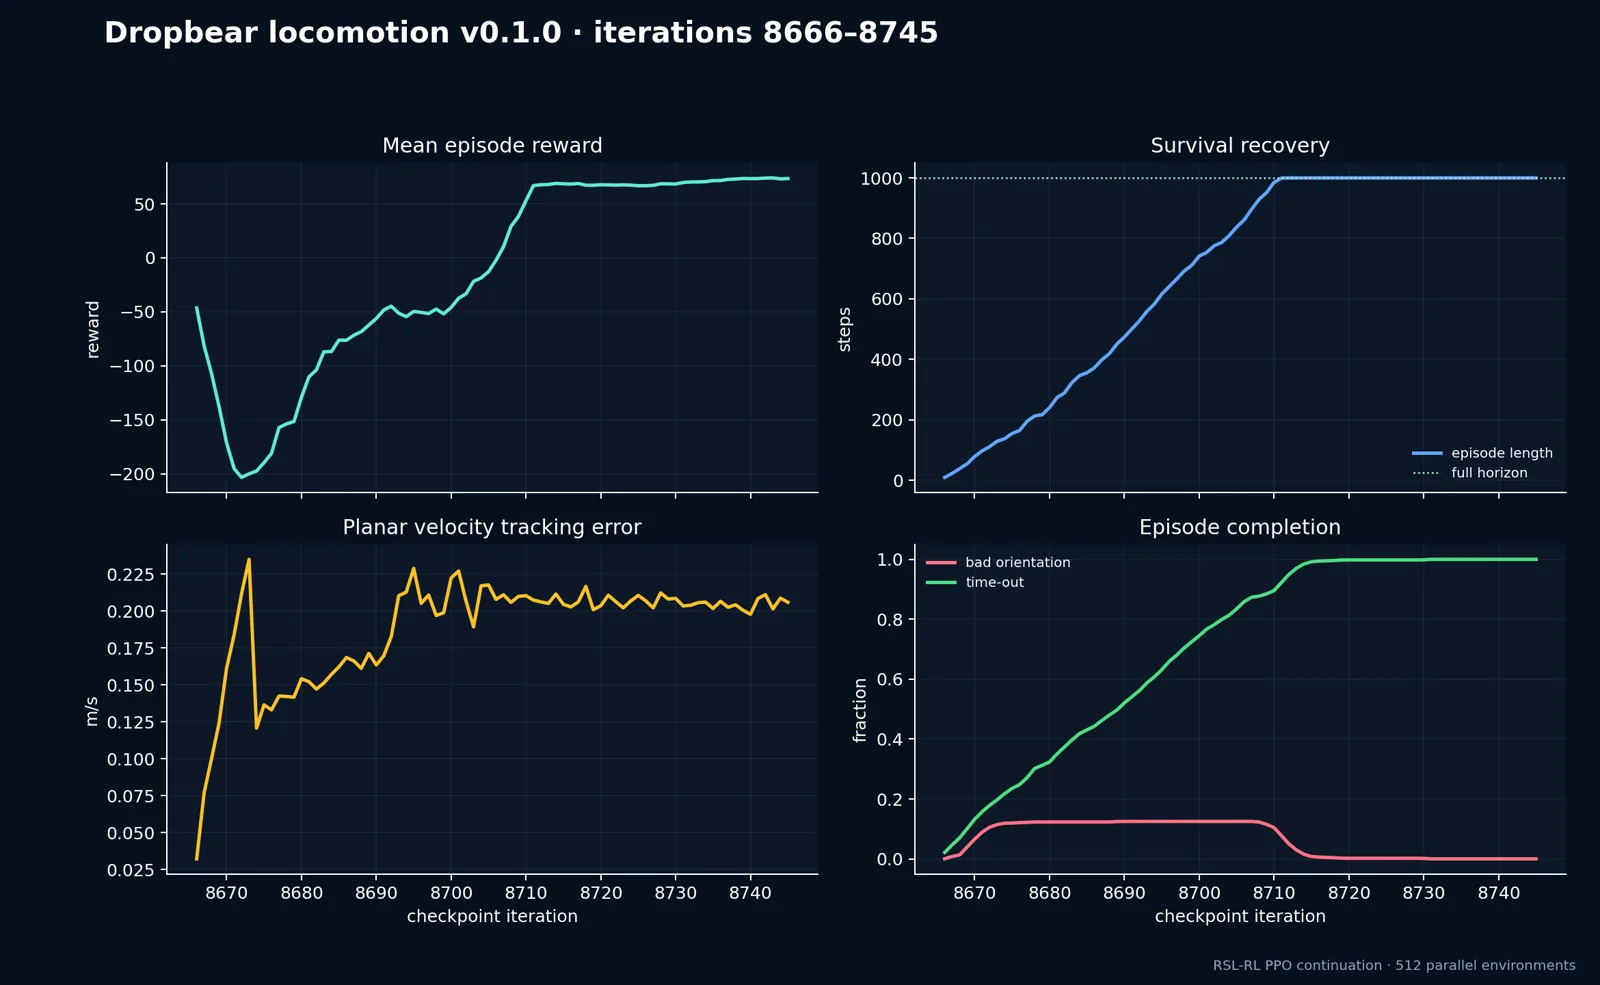
RSL-RL PPO continuation, 512 parallel environments: reward and survival recover to the full 1000-step horizon.Hyperspawn Robotics and robit-man (dropbear-locomotion) · CC-BY-NC-SA-4.0 · source 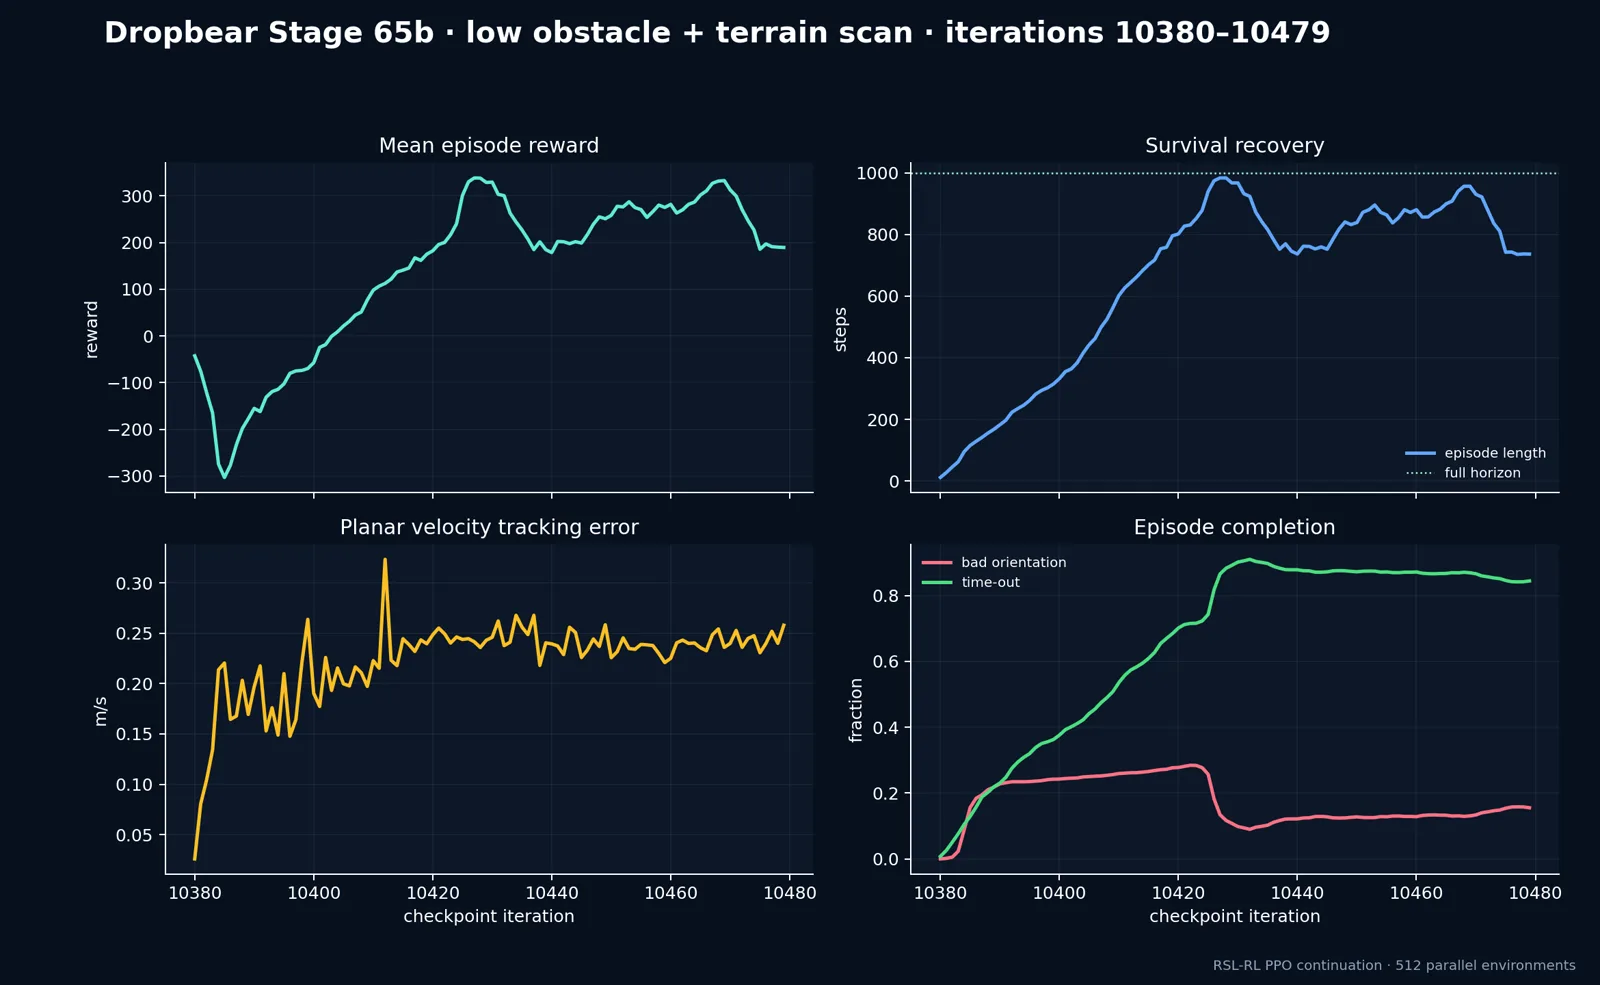
Stage 65b (low obstacle + terrain scan): survival peaks near the horizon, then about 15 % of episodes still end in bad orientation.Hyperspawn Robotics and robit-man (dropbear-locomotion) · CC-BY-NC-SA-4.0 · source
- 3D model: Interactive 3D model of Dropbear with hands, riggedHyperspawn · Hyperspawn · source
Spec card
12/13 known- Degrees of freedom
- 32
- Height
- 180 cm
- Mass
- 45 kg
- Payload
- 5 kg
- Runtime
- 120 min
- Battery
- 960 Wh
- Price
- $9,999 · Pre-assembled kit, $500 refundable deposit, ships Q2 2027 (first 500 units) per hyperspawn.ai. Options: five-finger hand +$1,000, Jetson Orin compute +$2,000, advanced policies +$4,000, covered shell +$500. Self-sourced BOM ~$10,400 (~$8,900 with a Jetson Orin NX); hyperspawn.ai quotes $1.5–3k in parts for a source build, which does not match the BOM.
- BOM total
- $9,948 · 86/94 lines priced
- Part count
- 1835
- Actuators
- MyActuator RMD-X10, RMD-X8, RMD-X6 and CEM-60 over 1 Mbit/s CAN (18 per the 2026 BOM; myactuator-can lists 12 RMD-X8 Pro, 4 RMD-X10 V3, 6 CEM-60); 6 NEMA 17 lead-screw steppers in the Stewart-platform neck. hyperspawn.ai: servo + QDD.
- Compute
- NVIDIA Jetson AGX Orin 64GB (BOM; Orin NX 16GB alternative) plus one ESP32-DevKitC-V4 CAN node per limb. Kit: Raspberry Pi 5 base, Jetson Orin advanced.
- Sensors
- Intel RealSense D455f depth camera, IMU (center-IMU controller role), foot load cells (4x HX711 per foot, dropbear-feet), actuator encoders; five AS5600 magnetic angle sensors per leg controller (observation-safe firmware)
Not in the registry: speed. Left blank rather than guessed.
What you learn building it
- +Whole-body control
- +Dozens of actuators on one bus
- +Balance and fall handling
- +Safe bring-up of a full-size machine
- +FDM 3D printing: 296 parts, about 460 h of printing
- +Tools used: FDM printer, 220x220x250 mm minimum (validated on a Bambu Lab P1S), Calipers, Bambu Studio or PrusaSlicer, FDM printer, FDM printer with a TPU-capable extruder, Flush cutters, Drill bits matching M3/M4/M5/M8 clearance, 220-400 grit sandpaper +37
- +40 assembly steps across 11 subassemblies
- +Flashing firmware for left_arm, right_arm, left_leg, right_leg, head, torso, neck (Dropbear-Neck-Assembly), feet (dropbear-feet pressure.ino)
- +Testing in simulation (URDF/MJCF) before touching hardware
- +Running published learned policies
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- publicPolicies
Score 100/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: MIT AND Hyperspawn-License. Software license: MIT AND CC-BY-NC-SA-4.0.
Repos & models
- github.com/Hyperspawn/Dropbear
- github.com/Hyperspawn/dropbear_hardware
- github.com/Hyperspawn/dropbear_printables
- github.com/Hyperspawn/dropbear_bom
- github.com/Hyperspawn/dropbear_docs
- github.com/Hyperspawn/dropbear_electronics
- github.com/Hyperspawn/dropbear_firmware
- github.com/Hyperspawn/Dropbear-Neck-Assembly
- github.com/Hyperspawn/dropbear-feet
- github.com/Hyperspawn/dropbear_urdf
- github.com/Hyperspawn/dropbear_mjcf
- github.com/Hyperspawn/dropbear_sim
- github.com/Hyperspawn/dropbear_gazebo
- github.com/Hyperspawn/dropbear_isaac
- github.com/Hyperspawn/dropbear_rl
- github.com/Hyperspawn/dropbear-locomotion
- github.com/Hyperspawn/dropbear_ros
- github.com/Hyperspawn/dropbear_rviz
- github.com/Hyperspawn/dropbear_brain
- github.com/Hyperspawn/dropbear_teleop
- github.com/Hyperspawn/dropbear_sim2real
- github.com/Hyperspawn/dropbear_testing
- github.com/Hyperspawn/dropbear_media
- github.com/Hyperspawn/myactuator-can
- github.com/Hyperspawn/actuator-testbench
- github.com/Hyperspawn/openqdd-hs
- github.com/Hyperspawn/opencycloid-hs
- github.com/robit-man/dropbear_control
Build it
Has an ORP build package.Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
None. This is the top. Find people building it on humanoidrobots.team.
This is the top of the ladder.
NoteReference implementation of the ORP spec; gets no ranking advantage anywhere in the suite. Three ways to get one: preorder the assembled kit ($9,999, $500 deposit, Q2 2027), self-source from the open BOM, or print and build from the repos. Level 2 (sim-verified), not 4: no physical walking is published and the locomotion repo calls its policies simulation releases; the v0.1.0 policy passed 128/128 zero-fall 20 s trials at 0.20 m/s in sim, so no top speed is listed. Spec sources conflict and the most recent official statement (hyperspawn.ai, 2026) is used: 1.8 m (home page says 6 ft), 45 kg (URDF sums to 47.7 kg, MJCF to 34.0 kg), 32 DOF (dropbear_firmware configures 31 joints across 6 limb nodes; the locomotion policy drives 14), 48 V battery (home-page label reads 24 V), 2–4 h runtime (lower bound stored). Battery energy is the BOM's 48 V 20 Ah pack. Licenses: most sub-repos are MIT (bom.md's footer says CC BY 4.0); the main Dropbear repo uses the non-commercial Hyperspawn License; dropbear-locomotion (code, weights, USD, media) is CC BY-NC-SA 4.0.
Sources
- [1]hyperspawn.ai: configure & preorder (price, deposit, ship date, specs)checked 2026-09-25
- [2]hyperspawn.ai: Dropbear spec sheetchecked 2026-09-25
- [3]hyperspawn.ai home (6 ft / 45 kg / 32 joints)checked 2026-09-25
- [4]hyperspawn.co (legacy domain, same site)checked 2026-09-25
- [5]Dropbear main repo READMEchecked 2026-09-25
- [6]dropbear_bom / bom.md (2026-04 pricing)checked 2026-09-25
- [7]dropbear_docschecked 2026-09-25
- [8]dropbear_printables (.3mf plates, print settings)checked 2026-09-25
- [9]dropbear_firmware CAN config (6 limb nodes, 31 joints)checked 2026-09-25
- [10]myactuator-can (actuator list, CAN IDs, limits)checked 2026-09-25
- [11]Dropbear-Neck-Assembly (6-DOF stepper neck)checked 2026-09-25
- [12]dropbear-feet (load-cell feet)checked 2026-09-25
- [13]dropbear-locomotion (policies, evaluations)checked 2026-09-25
- [14]v0.1.0 evaluation: 128 trials, 0 fallschecked 2026-09-25
- [15]dropbear_urdfchecked 2026-09-25
- [16]dropbear_mjcfchecked 2026-09-25