HumanoidRoboParty (Shanghai RoboParty Technology)2025CN
ROBOTO_ORIGIN
Fully open-source DIY running/jumping humanoid prototype whose structure, electronics, training and deployment code are all published; buildable from Taobao parts and JLC prototyping.
Difficulty index
10.8/13| Class | humanoid | +5 |
|---|---|---|
| Cost | unknown · midpoint | +1.5 |
| DOF | 23 DOF | +2.3 |
| Parts | 1336 parts | +2 |
Top of the ladder. This robot lives on the humanoid domains.
Specimen photographs
4 items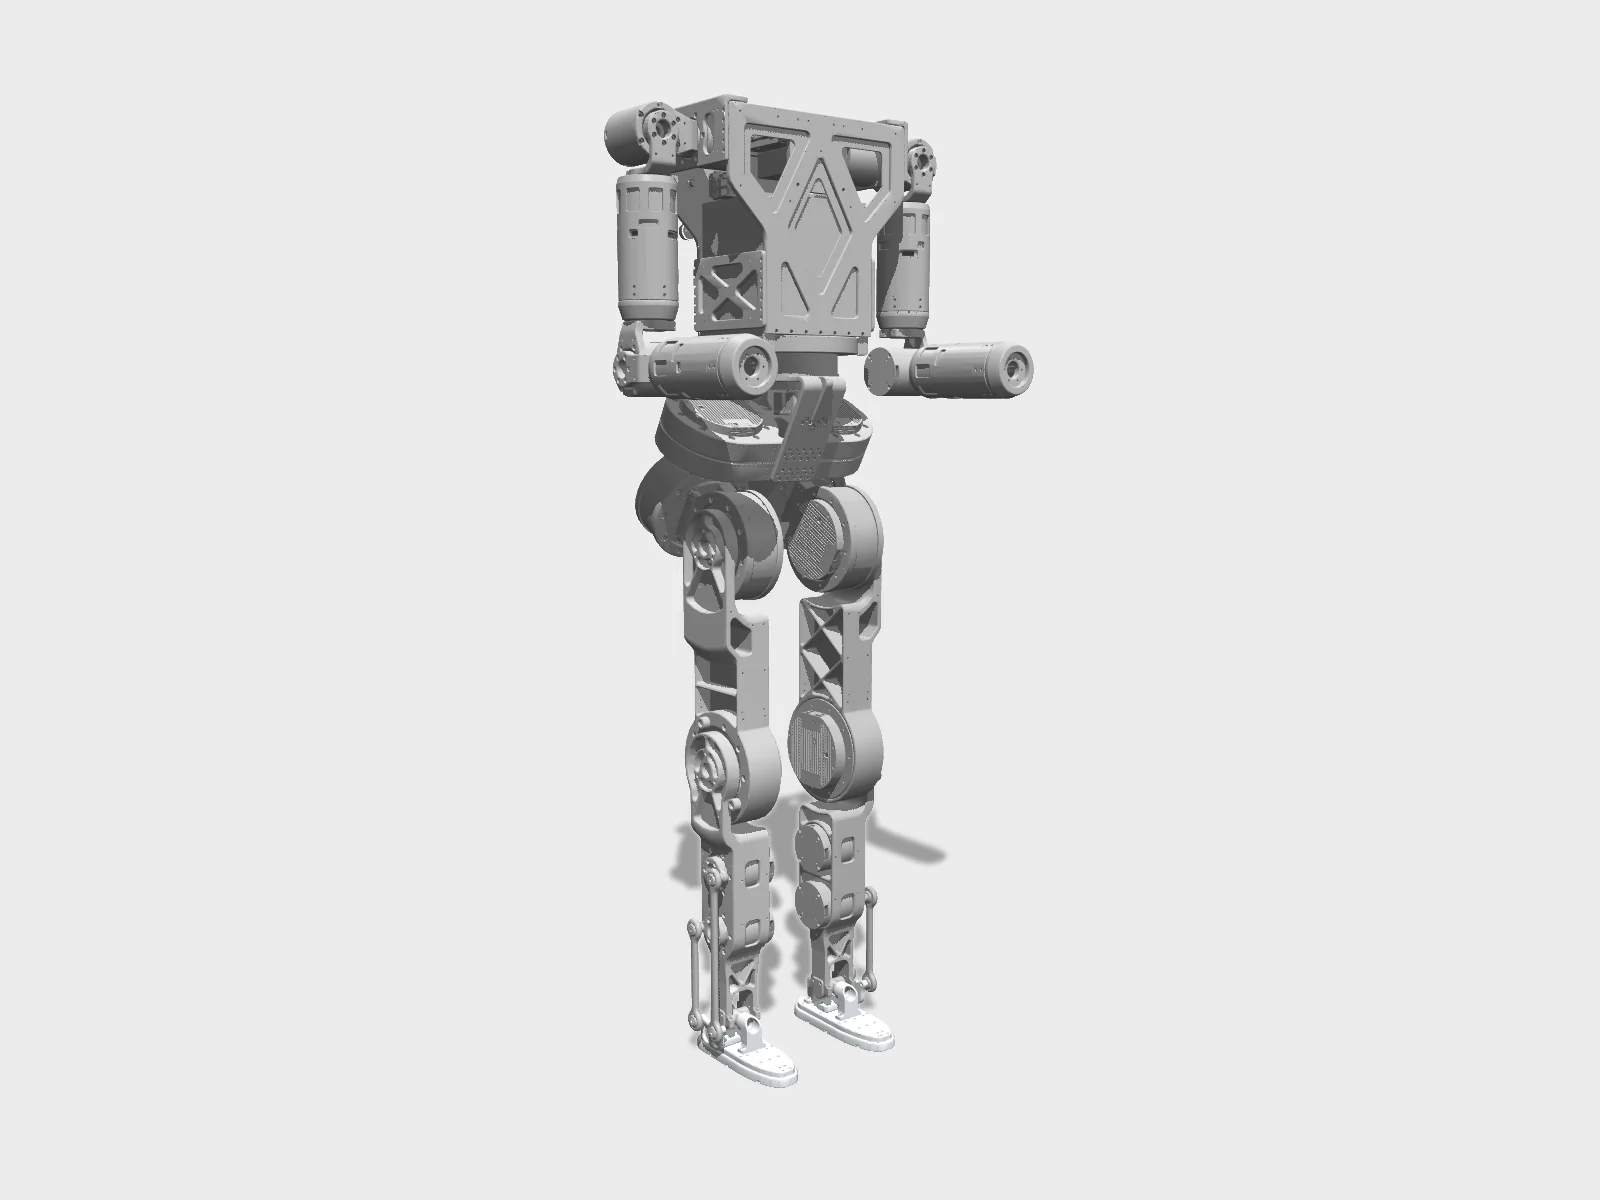
Studio render of the published MJCF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from Roboparty/roboto_origin (GPL-3.0) · Hyperspawn render · source 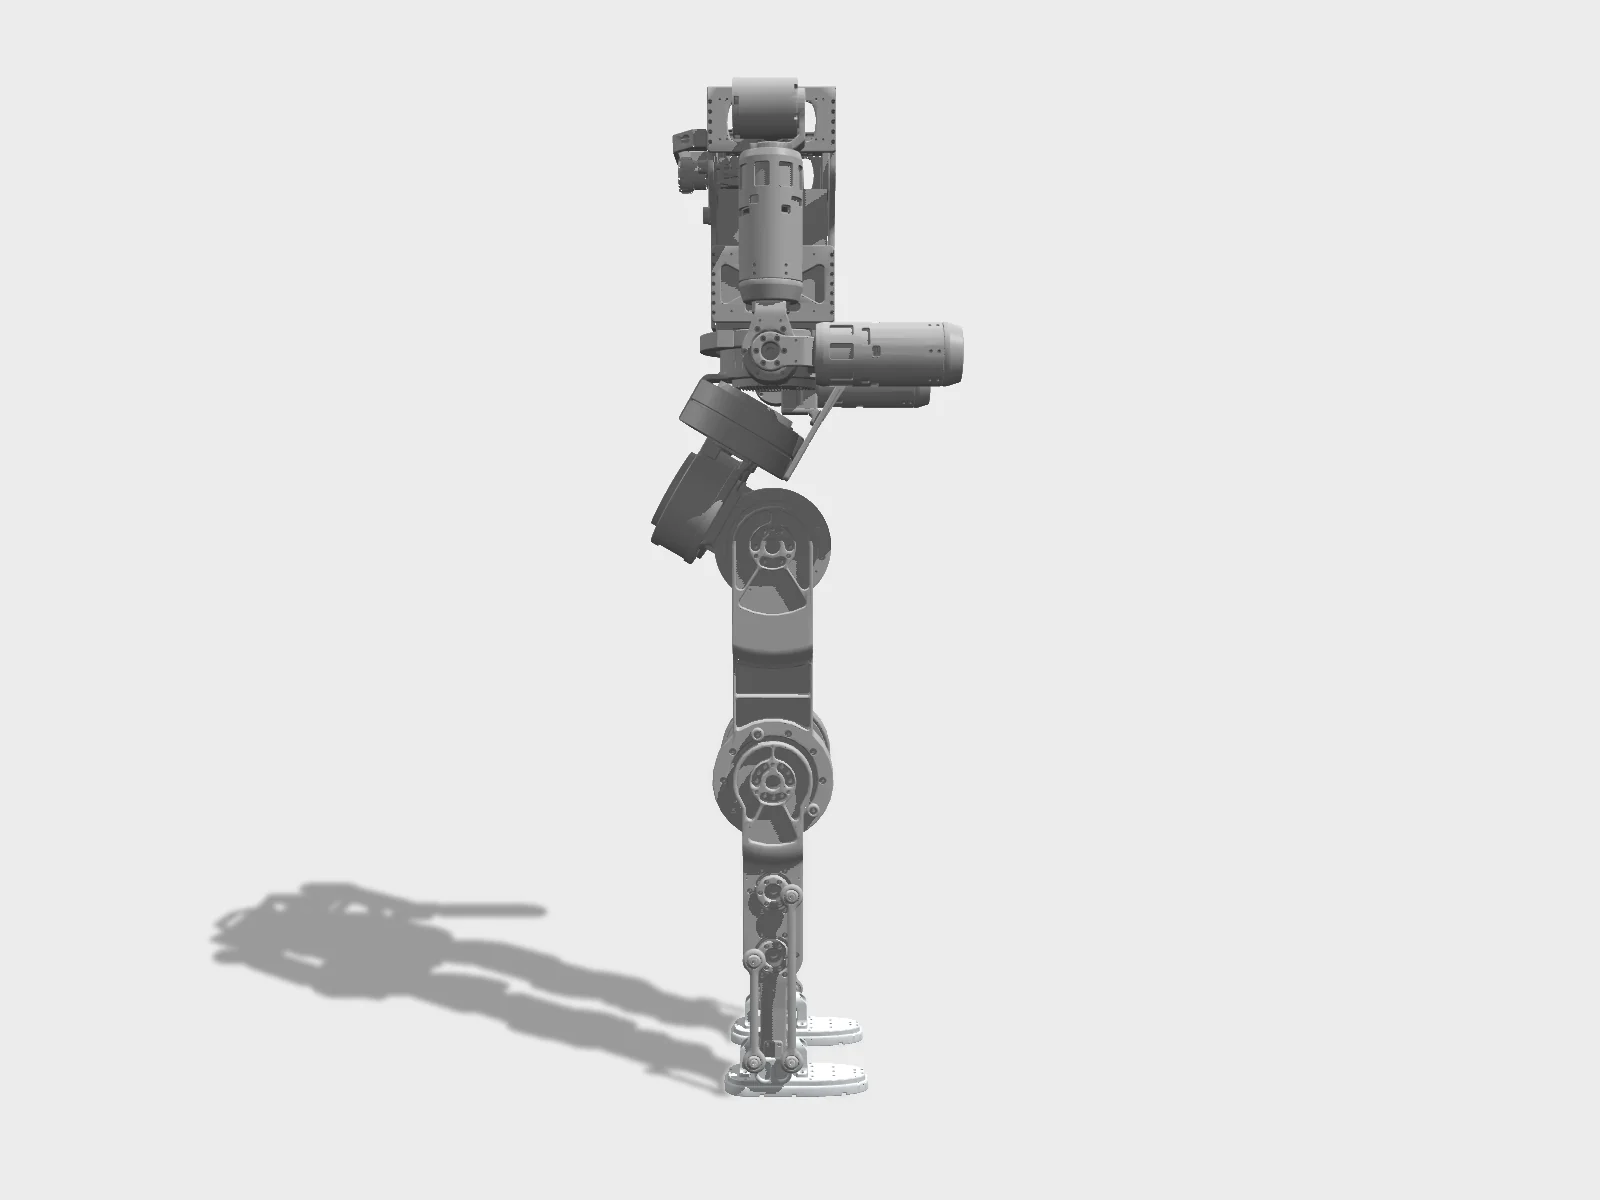
Side view of the same MJCF render, the model's zero pose.Rendered by Hyperspawn from Roboparty/roboto_origin (GPL-3.0) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from Roboparty/roboto_origin (GPL-3.0) · Hyperspawn render · source 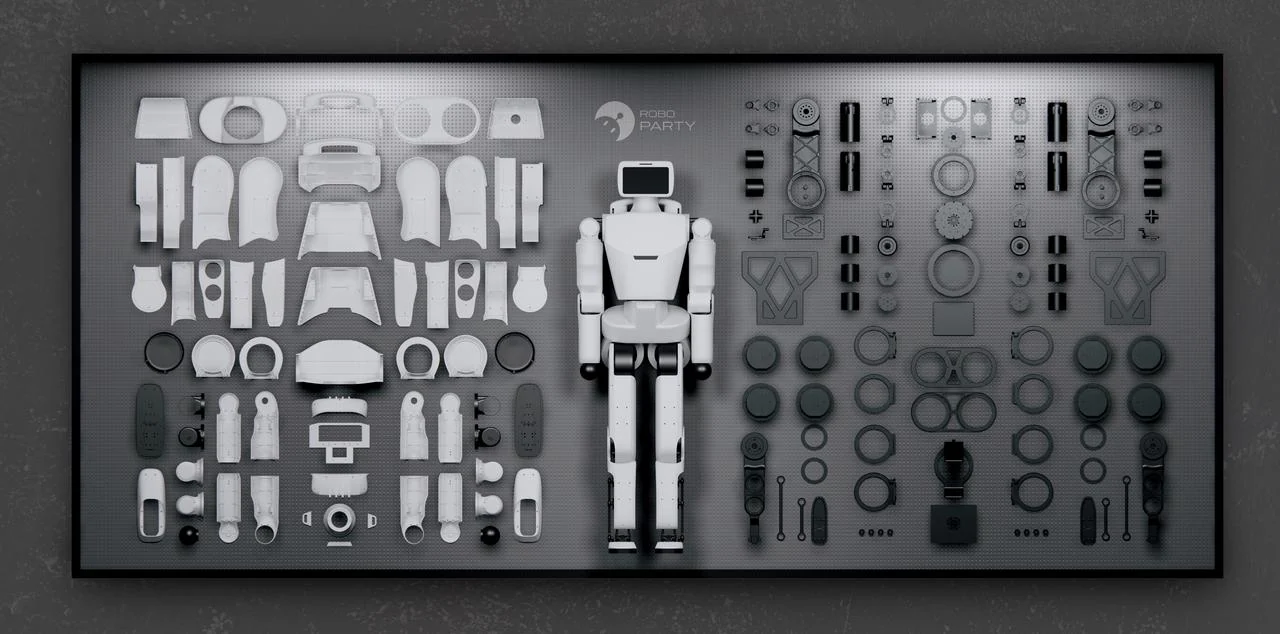
Flat-lay of printed and machined parts, from the roboto_origin README.Roboparty (roboto_origin) · GPL-3.0 · source

Spec card
8/13 known- Degrees of freedom
- 23
- Height
- 125 cm
- Mass
- 34 kg
- Speed
- 3 m/s
- Runtime
- 120 min
- Part count
- 1336
- Actuators
- 120 N·m peak joint torque (maker claim)
- Sensors
- Intel D435i depth camera and 3D LiDAR (both optional)
Not in the registry: payload, battery, price, bom total, compute. Left blank rather than guessed.
What you learn building it
- +Whole-body control
- +Dozens of actuators on one bus
- +Balance and fall handling
- +Safe bring-up of a full-size machine
- +CNC machining: 64 parts
- +FDM 3D printing: 16 parts
- +Tools used: FDM printer, Digital multimeter, Damiao host tool, Hex keys, Hand press, Thread locker, Electric screwdriver, Hammer +7
- +20 assembly steps across 10 subassemblies
- +Flashing firmware for RBE board USB-to-CAN (4x STM32G431), RDK X5 image (x5-rdk-gen), Orange Pi 5 Plus image / RT kernel (orangepi-build), Damiao DM-J4340P / DM-J10010L motor IDs (vendor tool)
- +Testing in simulation (URDF/MJCF) before touching hardware
- +Running published learned policies
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- publicPolicies
Score 100/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: CERN-OHL-W-2.0. Software license: GPL-3.0-only.
Repos & models
Build it
Has an ORP build package.Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
None. This is the top. Find people building it on humanoidrobots.team.
This is the top of the ladder.
NoteCompany founded Feb 2025; prototype built in ~4 months. Repo created Dec 2025, actively updated. Uses Isaac Lab / ROS 2. roboto_origin is a snapshot aggregation of the module repos. Specs are maker claims from the Original-0310 brochure in rpo_hardware (not in the README): 1.25 m, 34 kg, 23 DOF, 3 m/s, 120 N·m peak joint torque, 48 V 15 Ah battery, >2 h runtime. URDF and MJCF in modules/rpo_description. Licensing is per module (LICENSES.md): hardware (rpo_hardware, rpo_description, rpo_appearance) CERN-OHL-W-2.0; RoboParty software and firmware GPL-3.0-only; rpo_hardware docs CC-BY-SA-4.0; roboparty_train BSD-3-Clause; orangepi-build GPL-2.0. RoboParty names and logos are not licensed. Walking, motion-tracking, get-up and parkour policies ship as ONNX in roboparty_inference / roboparty_deploy.
Sources
- [1]Official repo READMEchecked 2026-09-24
- [2]roboto_origin LICENSES.md (per-module license scope)checked 2026-09-25
- [3]rpo_hardware LICENSES.md (CERN-OHL-W-2.0 / GPL-3.0-only / CC-BY-SA-4.0)checked 2026-09-25
- [4]ROBOTO Origin brochure (1.25 m, 34 kg, 23 DOF)checked 2026-09-25
- [5]roboparty_inference: ONNX policieschecked 2026-09-25