ArmAlexander Koch / Hugging Face LeRobot2024US
Koch v1.1 Low-Cost Robot Arm
Dynamixel-based low-cost leader/follower arm pair; an assembly-friendly revision of Alexander Koch's low_cost_robot, used in early LeRobot work.
Difficulty index
4.9/13| Class | arm | +2 |
|---|---|---|
| Cost | $461 BOM | +0.7 |
| DOF | unknown · midpoint | +1.5 |
| Parts | 51 parts | +0.7 |
Specimen photographs
5 items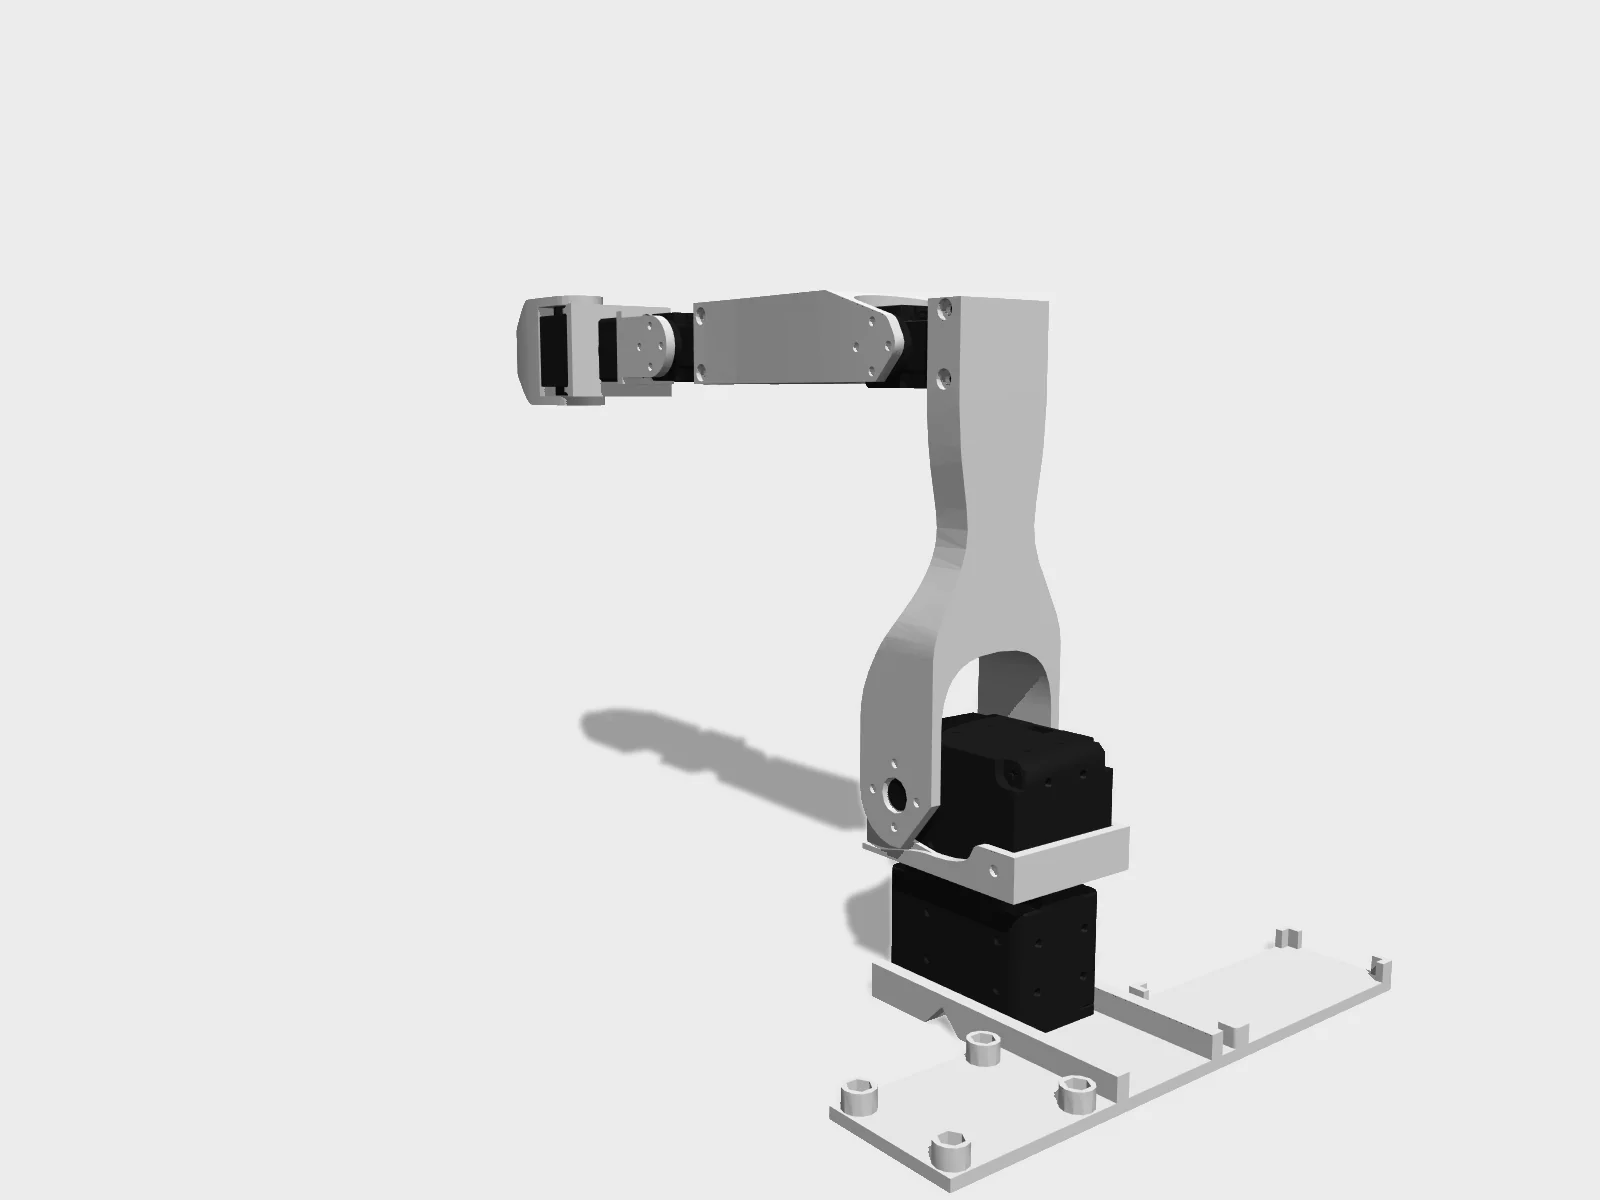
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/low_cost_robot_arm (Apache-2.0) · Hyperspawn render · source 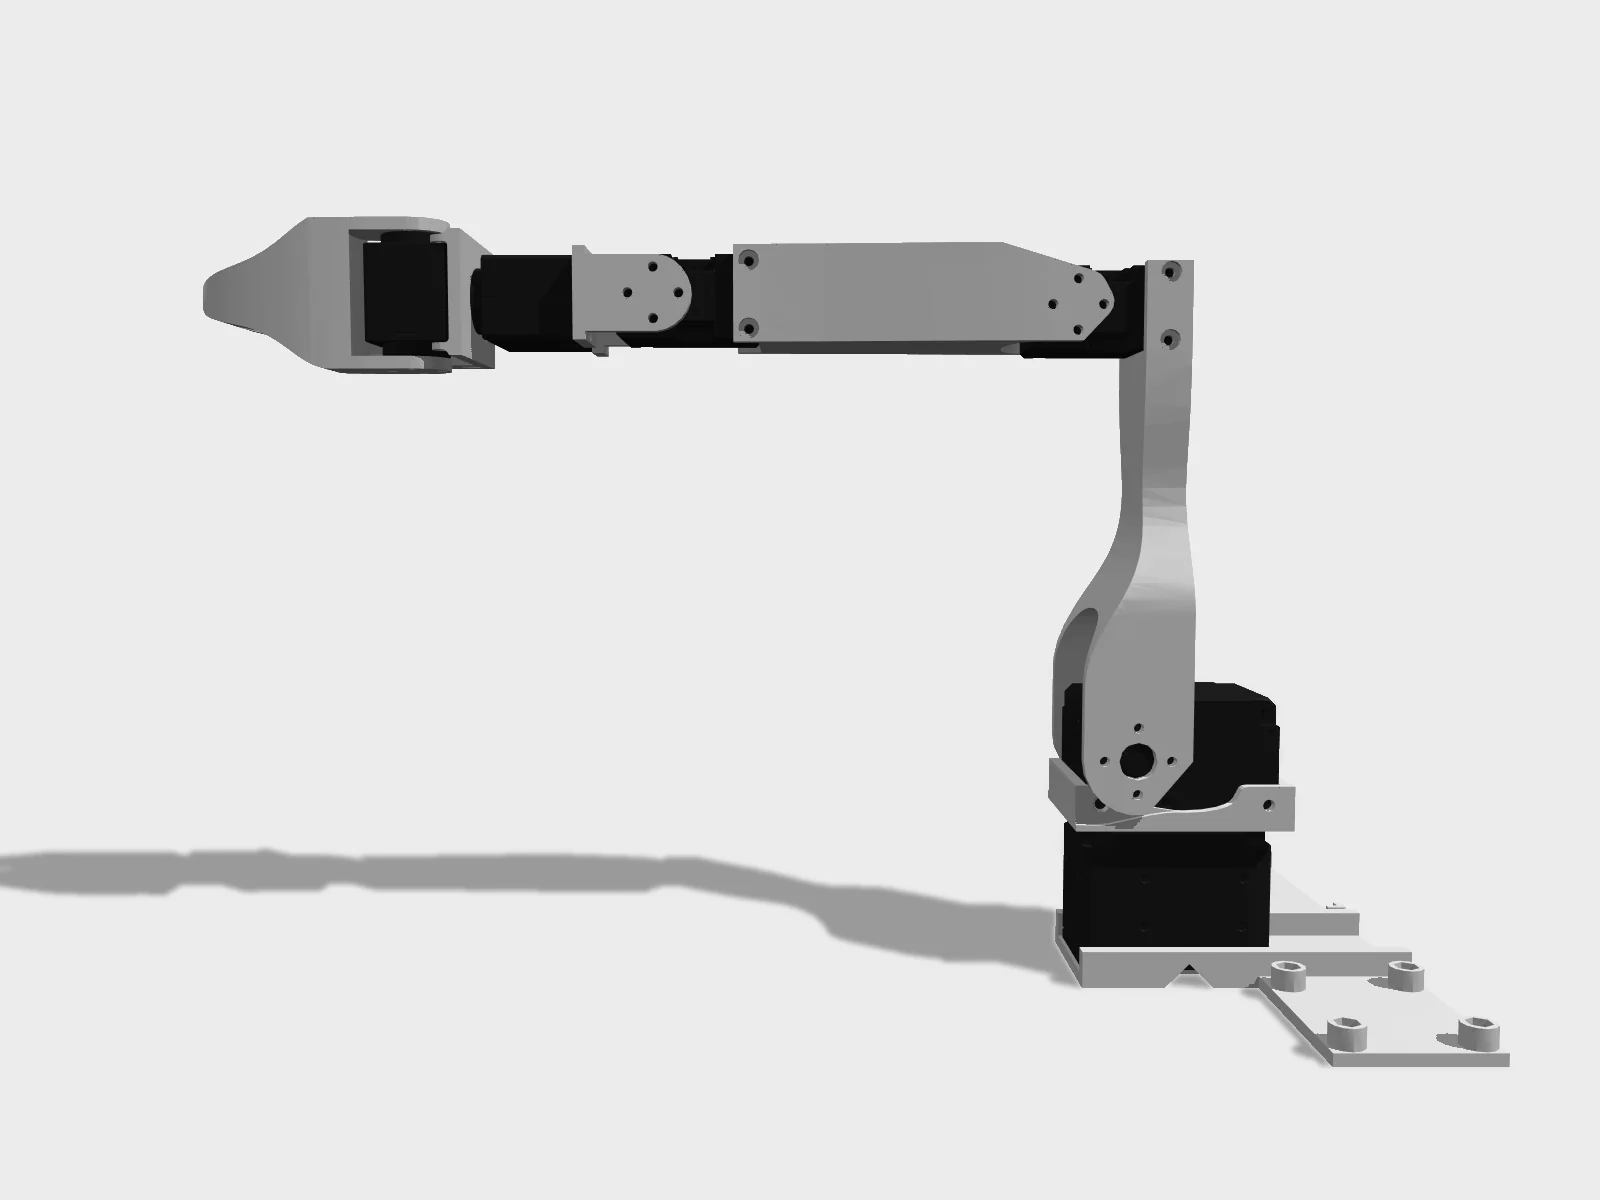
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/low_cost_robot_arm (Apache-2.0) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/low_cost_robot_arm (Apache-2.0) · Hyperspawn render · source 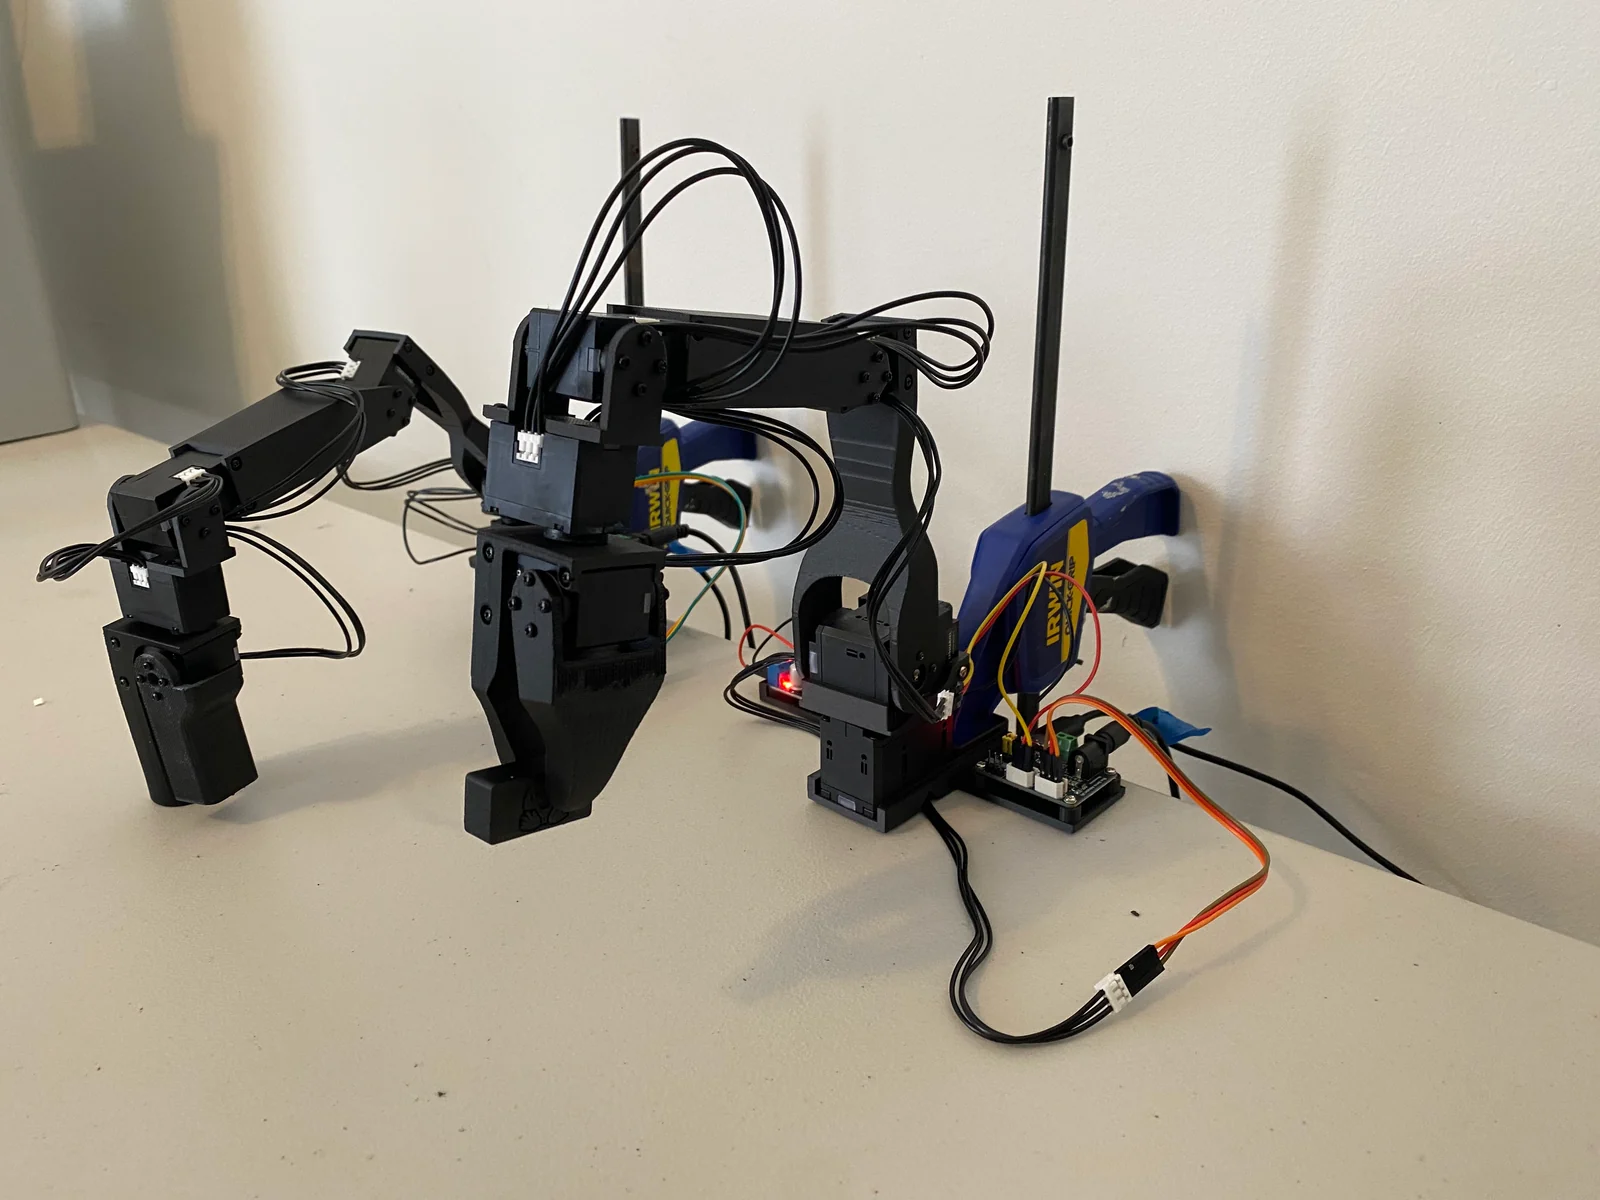
From the koch-v1-1 README.Jess Moss (koch-v1-1) · Apache-2.0 · source Low-Cost Robot Arm AssemblyAlexander Koch · official video, embedded · source

Spec card
3/13 known- BOM total
- $461 · 17/19 lines priced
- Part count
- 51
- Actuators
- Follower: Dynamixel XL430-W250-T x2 + XL330-M288-T x4; leader: XL330-M077-T x6
Not in the registry: degrees of freedom, height, mass, payload, speed, runtime, battery, price, compute, sensors. Left blank rather than guessed.
What you learn building it
- +Forward and inverse kinematics
- +Joint calibration and homing
- +Trajectory planning
- +Teleoperation and collecting demonstrations for learning
- +FDM 3D printing: 17 parts
- +Tools used: FDM printer (e.g. Prusa Mini+, Bambu P1, Ender 3), Glue stick, Putty knife, Linux or macOS computer, conda (miniforge), 1.5 mm cruciform screwdriver, Digital multimeter, NVIDIA GPU or Apple silicon
- +16 assembly steps across 8 subassemblies
- +Flashing firmware for Dynamixel XL430-W250-T (stock firmware), Dynamixel XL330-M288-T (stock firmware), Dynamixel XL330-M077-T (stock firmware), Waveshare Serial Bus Servo Driver Board (USB-serial, no user firmware)
- +Testing in simulation (URDF/MJCF) before touching hardware
Openness
- publicCAD
- publicBOM
- not publicFirmware
- publicSim model
- publicSoftware
- not publicPolicies
Score 75/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: Apache-2.0. Software license: Apache-2.0.
Repos & models
Build it
Has an ORP build package.- BOM total
- $461
- Lines priced
- 17/19
- Parts
- 51
- Steps
- 16
- Version
- 0.1.0
2 lines have no price yet, so the real total is higher.
Largest BOM lines
| Part | Qty | Unit |
|---|---|---|
| Dynamixel XL330-M077-T servo (leader arm, 5 V)XL330-M077-T (902-0162-000) | 6 | $24 |
| Dynamixel XL430-W250-T servo (follower shoulder pan + shoulder lift, 12 V)XL430-W250-T (902-0135-000) | 2 | $50 |
| Dynamixel XL330-M288-T servo (follower elbow, wrist flex, wrist roll, gripper; 5 V)XL330-M288-T (902-0163-000) | 4 | $24 |
| 12 V to 5 V voltage reducer (feeds the four XL330 servos)EP-JY-DC5 (wiring diagram) | 1 | $14 |
| 12 V DC power supply (follower arm) | 1 | $12 |
| XL330 frame and idler wheel set FPX330-H101, 4 pcs (leader; 3 of 4 used)FPX330-H101 | 1 | $10 |
| Waveshare Serial Bus Servo Driver Board (leader, run at 5 V)Amazon ASIN B0CTMM4LWK (wiring diagram) | 1 | $10 |
| XL330 frame and idler wheel set FPX330-H101, 4 pcs (follower; 3 of 4 used)FPX330-H101 | 1 | $10 |
- No official Koch policy checkpoints are published by LeRobot; only datasets exist (e.g. lerobot/koch_pick_place_5_lego). The robots.ts 'policies: true' flag rests on community models, not an upstream release.
- USD prices are the README's 2024 US figures (leader total $199, follower $278); EUR/GBP/CNY/JPY prices are kept as notes. Robotis prices and Amazon listings may have changed since the repo's last commit (Sep 2024).
- UK links are filed under region EU and Japan links under GLOBAL because the registry has no UK or JP region.
- Taobao/Tmall URLs are the README links reduced to item id and skuId; several a.co short links resolve to Amazon listings that may be gone.
- Leader and follower tables both list the Waveshare board, jumpers and a table clamp; the screwdriver and USB cable sets are listed twice upstream but the footnotes say buy once, so they appear once here.
- The LeRobot Koch page powers the follower board from the 5 V supply during motor setup, while the README and wiring diagram run the follower at 12 V with a 12-to-5 V reducer for the XL330 chain. Both are consistent only if the 12 V supply is never used while an XL330 is plugged straight into the board (XL330 rated 3.7-6.0 V, XL430 6.5-12.0 V per the Robotis e-Manual). Whether the XL430s answer ID setup at 5 V is not stated upstream.
- The leader board runs at 5 V although the Waveshare board is rated 9-12.6 V; the README says this is intended (footnote 14).
- The assembly video predates the screwed Leader_Platform and the LeRobot motor-setup order; follow the README and LeRobot notes where they differ.
- No fastener list beyond the four M2x5 screws and M2 nuts for the platform: servo screws come with the Robotis frame/idler sets. Check the video for counts.
- No camera is in the BOM; recording datasets needs at least one USB camera.
- Repo is Apache-2.0; the original low_cost_robot is MIT. The repo has not changed since Sep 2024 and LeRobot now centres on SO-101.
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
Aero Hand Open →Chestnut Robotics (formerly TetherIA) · hand · index 5.5Easiest buildable hand, the next class up from arm. Adds tendon and linkage transmissions.
NoteRepo last pushed Sep 2024; LeRobot community has largely moved to SO-101. Original low_cost_robot is MIT-licensed. Uses stock Dynamixel firmware (firmware=false). policies=false: only datasets are published upstream.
Sources
- [1]Koch v1.1 repo (Apache-2.0, BOM, leader/follower totals)checked 2026-09-25
- [2]LeRobot Koch dataset (no official policy)checked 2026-09-25
- [3]Original low_cost_robot (MIT)checked 2026-09-24
- [4]MuJoCo Menagerie low_cost_robot_armchecked 2026-09-24
- [5]Alexander Koch on GitHub (location)checked 2026-09-24