ArmAnnin RoboticsUS
AR4
Open-plan, low-cost 6-DOF desktop industrial-style robot arm by Chris Annin, programmable via its HMI, Python or ROS.
Difficulty index
4.7/13| Class | arm | +2 |
|---|---|---|
| Cost | $699 BOM | +0.8 |
| DOF | 6 DOF | +0.6 |
| Parts | 185.12 parts | +1.3 |
Specimen photographs
5 items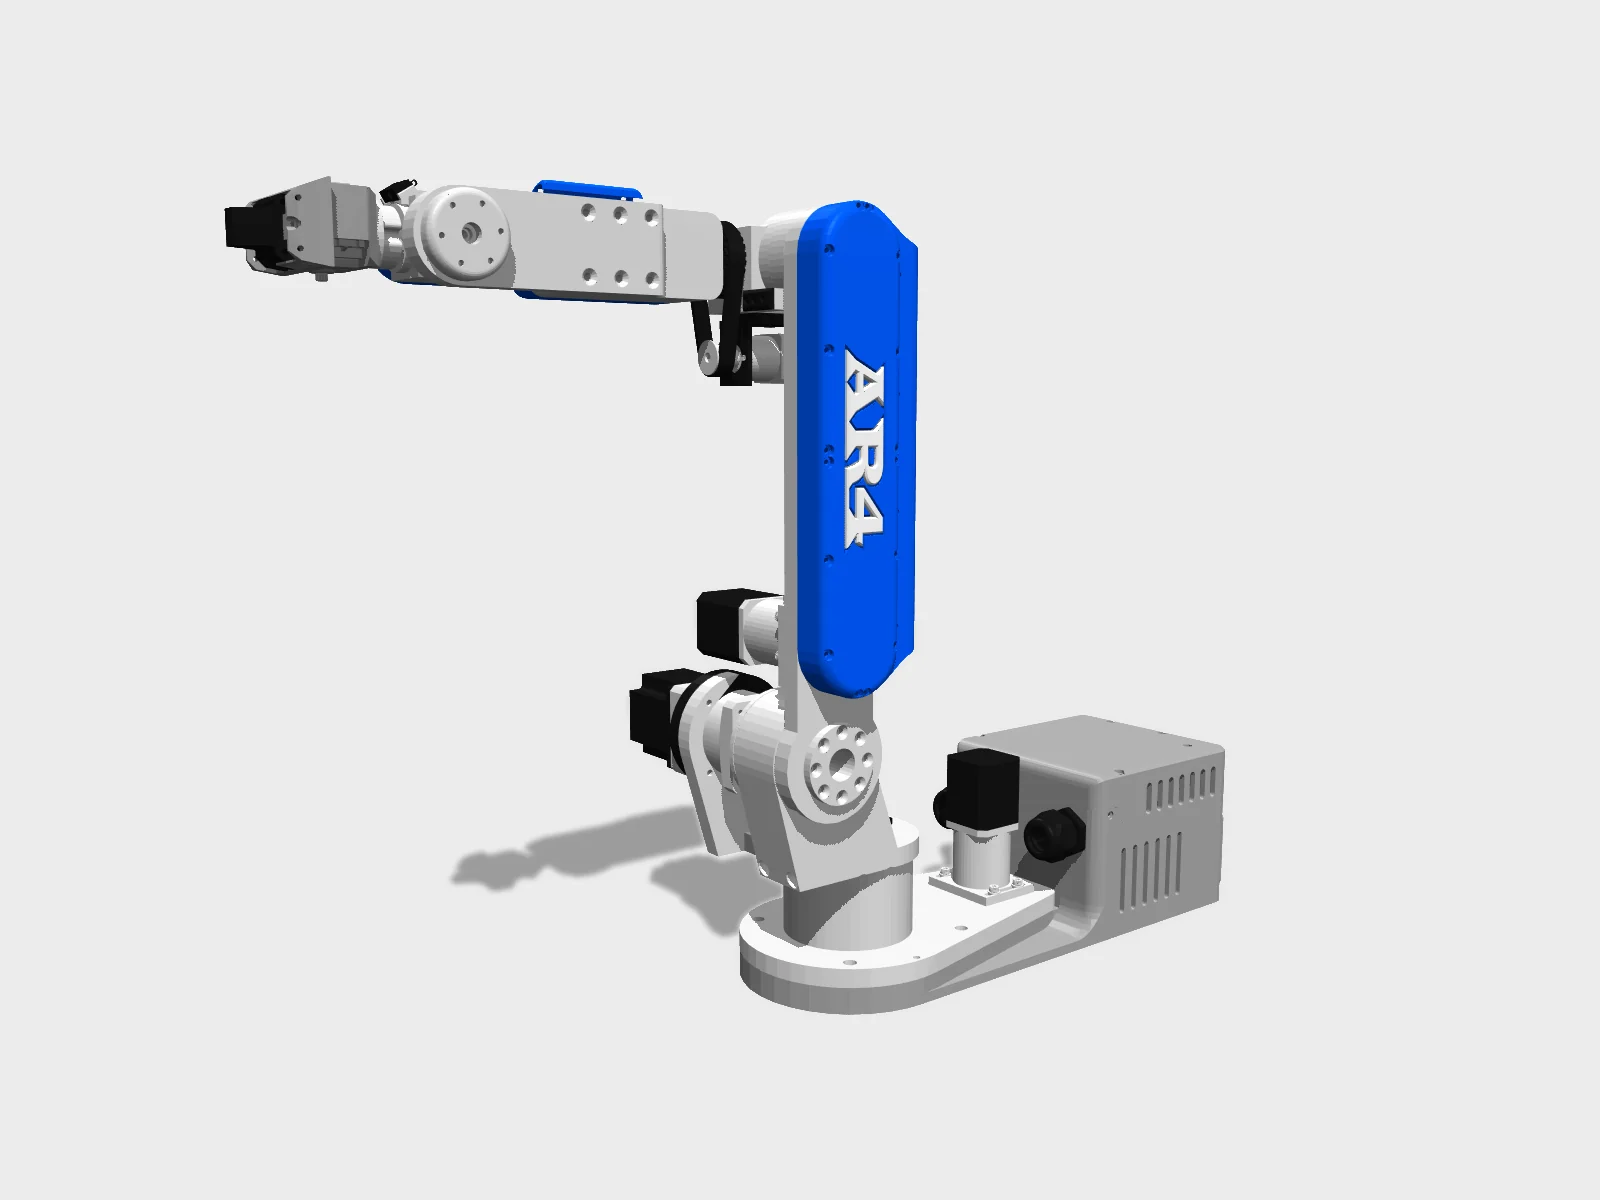
Studio render of the published URDF (xacro), the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from Annin-Robotics/ar4_ros_driver (MIT) · Hyperspawn render · source 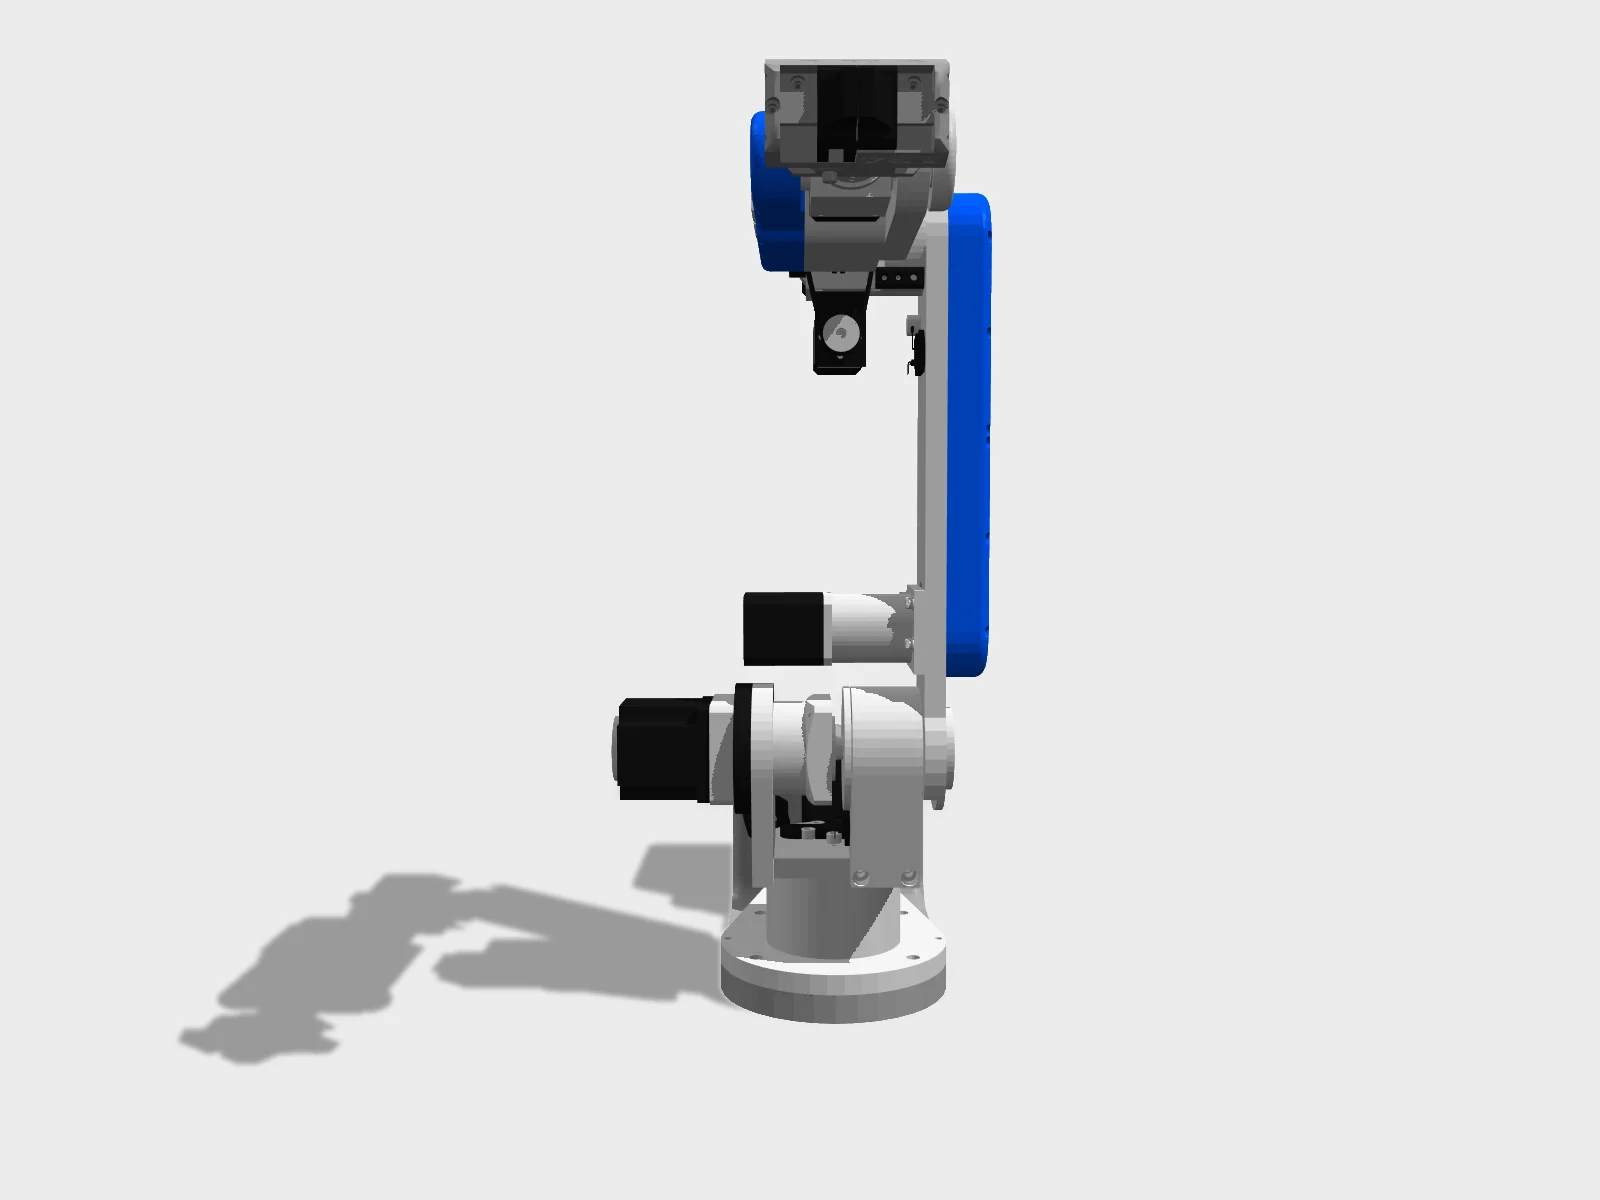
Side view of the same URDF (xacro) render, the model's zero pose.Rendered by Hyperspawn from Annin-Robotics/ar4_ros_driver (MIT) · Hyperspawn render · source 4 s turntable of the URDF (xacro) studio render.Rendered by Hyperspawn from Annin-Robotics/ar4_ros_driver (MIT) · Hyperspawn render · source Build Your Own Industrial Robot, AR4 6-Axis Open-Source Arm - Low Cost, Python ProgrammableChris Annin · official video, embedded · source AR4 MK5 Open Source Robot Arm | 6DOF Arduino Python ROS2 Automation RobotChris Annin · official video, embedded · source
Spec card
3/13 known- Degrees of freedom
- 6
- BOM total
- $699 · 1/64 lines priced
- Part count
- 185.12
Not in the registry: height, mass, payload, speed, runtime, battery, price, actuators, compute, sensors. Left blank rather than guessed.
What you learn building it
- +Forward and inverse kinematics
- +Joint calibration and homing
- +Trajectory planning
- +Teleoperation and collecting demonstrations for learning
- +FDM 3D printing: 31 parts
- +CNC machining: 27 parts
- +Tools used: FDM printer, Drill bits 3-3.5 mm, M3 and M4 taps, Drill bits, M3/M4 taps, Epoxy (printed build), Phillips screwdriver, 3 mm drill +21
- +22 assembly steps across 8 subassemblies
- +Flashing firmware for Teensy 4.1 (arm: step/dir to 3x DM332T + 3x DM320T, 6 motor encoders, calibration inputs pins 26-31, E-stop pin 39), Arduino Nano or Mega (optional gripper / IO board, 5 V)
- +Testing in simulation (URDF/MJCF) before touching hardware
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- not publicPolicies
Score 90/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: Annin-Robotics-NC-1.1. Software license: MIT AND Annin-Robotics-NC-1.1.
Repos & models
Build it
Has an ORP build package.- BOM total
- $699
- Lines priced
- 1/64
- Parts
- 185.12
- Steps
- 22
- Version
- 0.1.0
63 lines have no price yet, so the real total is higher.
Largest BOM lines
| Part | Qty | Unit |
|---|---|---|
| AR4 MK5 Aluminum Parts Kit (26 machined structural pieces) | 1 | $699 |
| J1 gear motor, NEMA 17 with 10:1 planetary gearbox and encoder17HS15-1684D-EG10-AR4 | 1 | ? |
| J2 gear motor, NEMA 23 with 50:1 gearbox and encoder23HS22-2804D-YGS50-AR4 | 1 | ? |
| J3 gear motor, NEMA 17 with 50:1 planetary gearbox and encoder17HS15-1684D-EG50-AR4 | 1 | ? |
| J4 gear motor, NEMA 11 with 16:1 gearbox and encoder11HS20-0674D-EGS16-AR4 | 1 | ? |
| J5 linear drive motor, NEMA 17 lead-screw motor with encoder (remove the POM nut before assembly)17LS19-1684E-200G-AR4 | 1 | ? |
| J6 gear motor, NEMA 14 with 20:1 gearbox and encoder14HS11-1004D-EGS20-AR4 | 1 | ? |
| DM332T digital stepper driver (J1, J2, J3)DM332T | 3 | ? |
- Upstream pins: AR4-MK5 Robot Manual v1.1 (version log 6/8/26; PDF at anninrobotics.com, 390 pages) as of 2026-09-25; AR4-MK5-3D-Print-Files.zip (2026-06 upload); AR4-MK5-motor-step-calculations.xlsx; downloads and robot-kits pages as of 2026-09-25 (Teensy sketch v7.0, HMI 7.0); Annin-Robotics/ar4-hmi@ed2abfd3a33340745dd4e2e114a7b1ac6761fc29 (2025-11-19, HMI 6.3.1, Teensy sketch v6.3); Annin-Robotics/ar4_ros_driver@6a3ebb11cedab12cd1d29b41d63aa270a008ab8b (2026-06-09, Teensy firmware 2.1.0, ar_model mk1-mk5)
- Only kit-level USD prices are published: MK5 Combo Kit $1,189, Aluminum Parts Kit $699, Hardware Kit $319, Electrical Parts Kit $229, Pneumatic Gripper Parts Kit $139, Servo Gripper Parts Kit $74.50, MK5 CAD (SolidWorks/STEP) $99. Individual parts, the StepperOnline motor/driver/PSU package and printed parts are unpriced here. Only the aluminium kit line carries a price, so any computed total is far below the real cost (robots.ts note: just over $2,000).
- The main robot BOM does not list a power supply. The 24 V 8 A adapter appears in the pneumatic gripper BOM and ships in the StepperOnline package; it is a mains brick feeding a 5.5 mm jack.
- Motor part numbers disagree inside the manual: the motor BOM pages list J2 23HS22-2804D-YGS50-AR4 and J6 14HS11-1004D-EGS20-AR4, while the DIP-switch table lists 23HS22-2804D-HG50 and 14HS13-0804D-PG19 (0.92 A). The BOM SKUs are used here; set the J6 driver current for the motor you actually receive.
- The manual cover says Version 1.0 but its version log records 1.1 (6/8/26: new J3 sensor mount, belt tension text). Build-manual PDFs are replaced on the downloads page without changelogs beyond that log.
- GitHub lags the website: ar4-hmi holds HMI 6.3.1 and Teensy sketch v6.3 (2025-11), while anninrobotics.com offers HMI 7.0 and sketch v7.0 (2026-07). The sketch and HMI versions must match.
- The ROS driver README still lists ar_model options up to mk4, but driver.launch.py accepts mk5 and defaults to it. ROS use needs the separate annin_ar4_firmware sketch.
- Licensing: ar4-hmi and the design files are under the Annin Robotics Open Source Non-Commercial License v1.1 (no commercial use; design files may not be redistributed or rehosted). Only ar4_ros_driver is MIT. STL files are free; SolidWorks/STEP CAD for MK5 is sold ($99).
- Fully printed builds are possible but the J4 main shaft must be aluminium tube, several large parts must be split and epoxied, and the manual notes belt tension cannot reach aluminium-build levels.
- Fastener table lists 'M3 x 6 Button Head screw' and 'M3x6 Button head' as separate one-off lines; both are kept. The page 28 table is grouped here into sets, counts unchanged.
- No trained policies or datasets for AR4 were found on Hugging Face (search 2026-09-25).
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
Aero Hand Open →Chestnut Robotics (formerly TetherIA) · hand · index 5.5Easiest buildable hand, the next class up from arm. Adds tendon and linkage transmissions.
NoteChris Annin declared the design complete with the final Mark 5 revision. ar4_ros_driver is MIT; ar4-hmi uses the Annin Robotics Open Source Non-Commercial License v1.1 (GitHub NOASSERTION), recorded as LicenseRef-Annin-Robotics-NC-1.1. The design files (STLs in ar4-hmi) fall under the same non-commercial license, so hw is LicenseRef-Annin-Robotics-NC-1.1: no commercial use, no rehosting. The current build is MK5 (AR4-MK5 build manual v1.1 on the downloads page). STL files are free; SolidWorks/STEP CAD for MK5 is sold separately ($99). sim=true refers to URDF in the ROS driver repo.
Sources
- [1]Annin downloads: AR4-MK5 build manual, STLs, softwarechecked 2026-09-25
- [2]ar4-hmi LICENSE.txt (Annin Robotics Open Source Non-Commercial License v1.1)checked 2026-09-25
- [3]Annin Robotics sitechecked 2026-09-24
- [4]Hackster: AR4 Mark 5 final revisionchecked 2026-09-24
- [5]Annin: ~$2000 build costchecked 2026-09-24