ArmStanford (Tony Zhao et al.)2023US
ALOHA
Low-cost open-source bimanual teleoperation system with two leader and two follower arms plus four cameras, used to collect data for ACT imitation learning.
Difficulty index
6.7/13| Class | arm | +2 |
|---|---|---|
| Cost | $19k BOM | +2.3 |
| DOF | unknown · midpoint | +1.5 |
| Parts | 80 parts | +0.9 |
Specimen photographs
4 items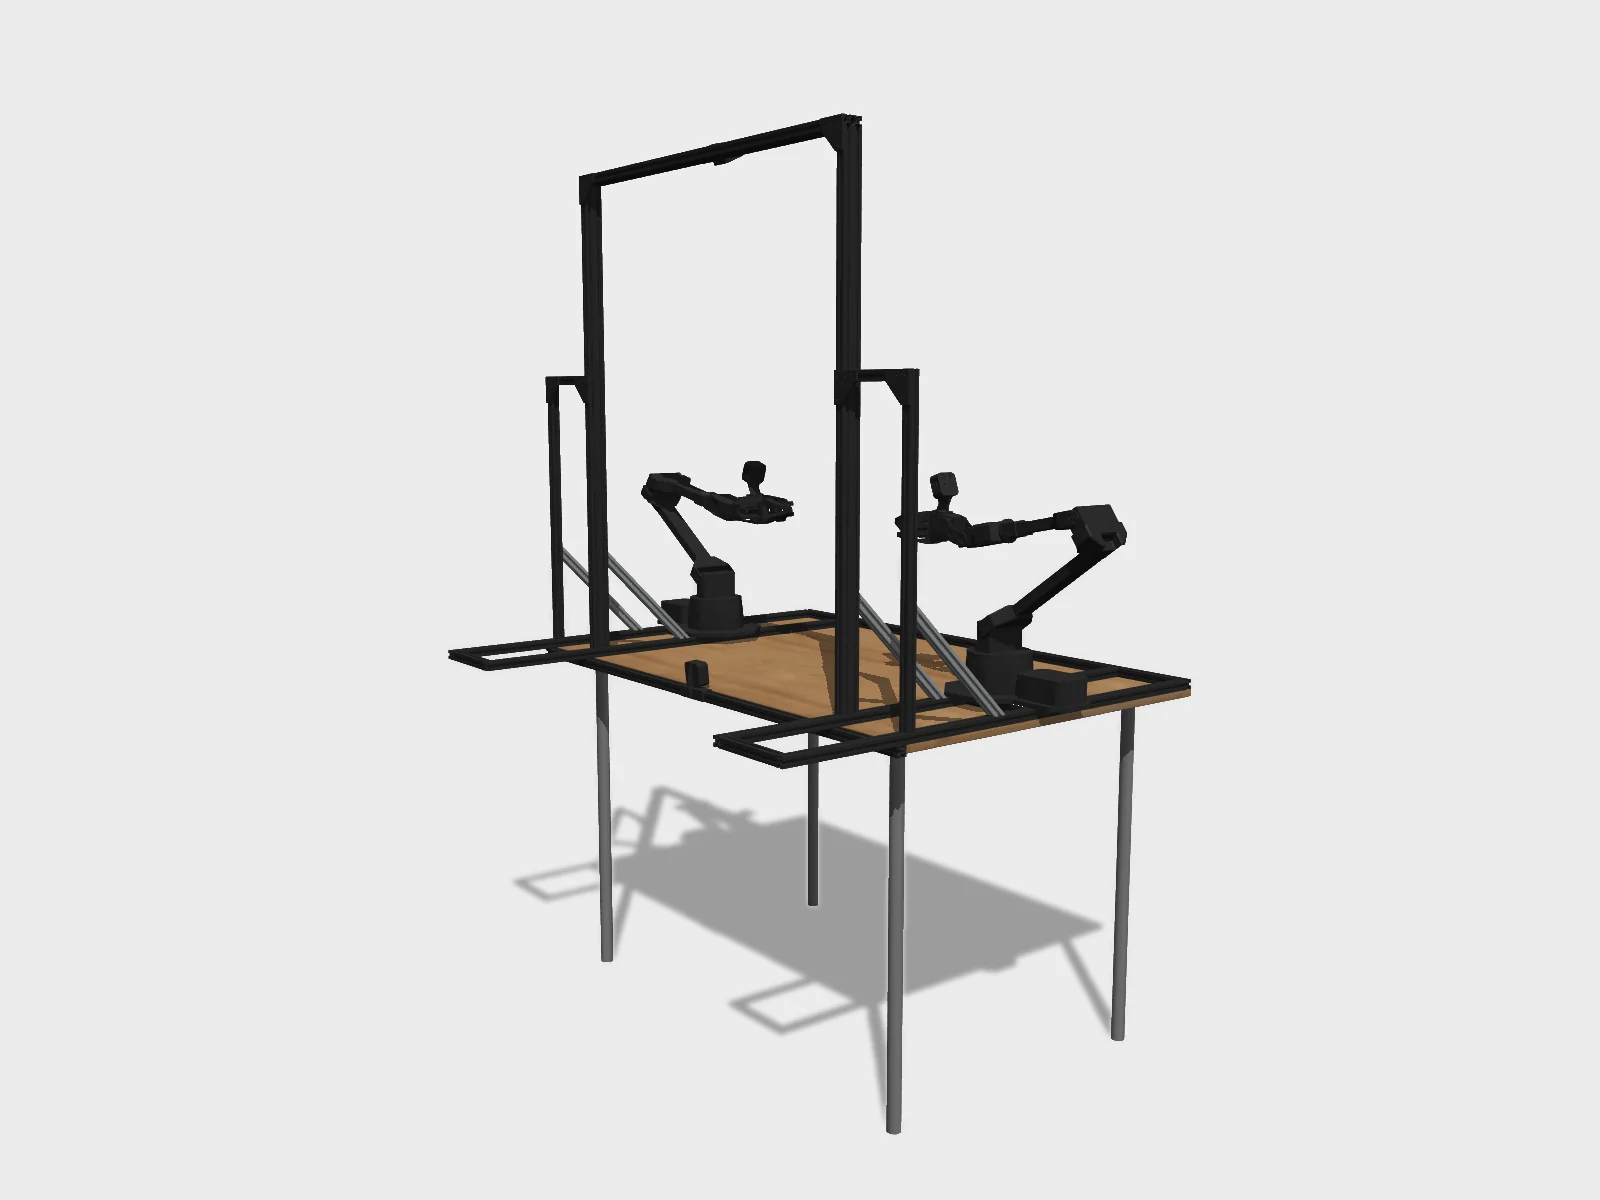
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/aloha (BSD-3-Clause) · Hyperspawn render · source 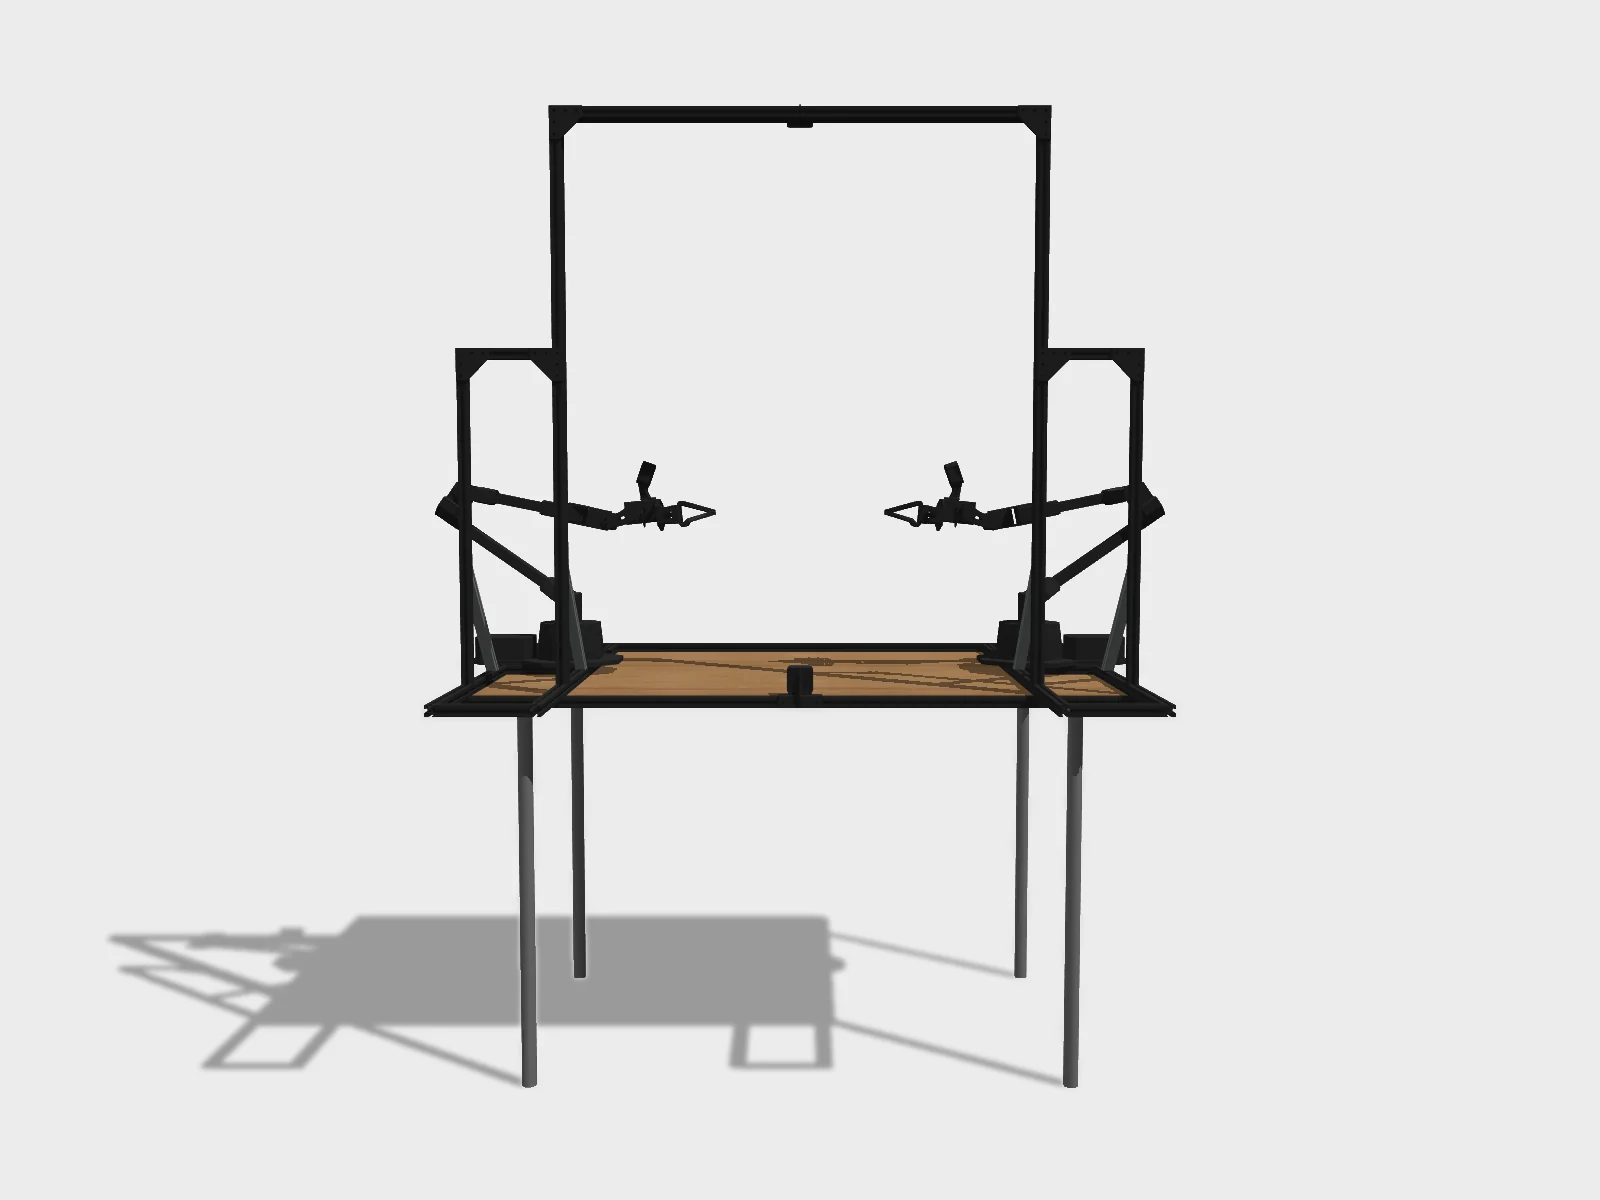
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/aloha (BSD-3-Clause) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/aloha (BSD-3-Clause) · Hyperspawn render · source ALOHA Robot at Stanford UniversityZipeng Fu · official video, embedded · source
Spec card
3/13 known- BOM total
- $19k · 23/34 lines priced
- Part count
- 80
- Sensors
- 4 cameras
Not in the registry: degrees of freedom, height, mass, payload, speed, runtime, battery, price, actuators, compute. Left blank rather than guessed.
What you learn building it
- +Forward and inverse kinematics
- +Joint calibration and homing
- +Trajectory planning
- +Teleoperation and collecting demonstrations for learning
- +FDM 3D printing: 25 parts
- +Tools used: FDM printer (~$300 class), Ultimaker Cura, Metal file set, Wire stripper, Crimp tool, Digital multimeter, Ubuntu 20.04 + ROS 1 Noetic (tested per README), Drill +7
- +23 assembly steps across 9 subassemblies
- +Flashing firmware for Interbotix X-series arms: stock Dynamixel firmware (gripper motor ID 9 is XM430-W350 on the ViperX), Robot USB interface (FTDI serial; udev bound to /dev/ttyDXL_*)
- +Testing in simulation (URDF/MJCF) before touching hardware
- +Running published learned policies
Openness
- publicCAD
- publicBOM
- not publicFirmware
- publicSim model
- publicSoftware
- publicPolicies
Score 85/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Software license: MIT.
Repos & models
Build it
Has an ORP build package.- BOM total
- $19k
- Lines priced
- 23/34
- Parts
- 80
- Steps
- 23
- Version
- 0.1.0
11 lines have no price yet, so the real total is higher.
Largest BOM lines
| Part | Qty | Unit |
|---|---|---|
| Trossen ViperX 300 Robot Arm 6DOF (puppet / follower arms)vx300s (Interbotix robot_model) | 2 | $5,695.95 |
| Trossen WidowX 250 Robot Arm 6DOF (master / leader arms)wx250s (Interbotix robot_model) | 2 | $3,295.95 |
| Logitech C922x Pro Stream webcam (2 wrist, 1 top, 1 front)C922x | 4 | $98.35 |
| Standing desk, 48x30 in, black | 1 | $199.99 |
| Aluminium extrusion bars, black, 10 pcs x 1220 mm (48 in) (yellow bars in frame CAD) | 1 | $99.99 |
| Corner bracket set, 20 sets, M5x8 (type 1 brackets) | 3 | $28.99 |
| Aluminium extrusion bars, black, 10 pcs x 1000 mm (39.4 in) (green bars) | 1 | $83.99 |
| Corner bracket, black, L-4 with screws (type 2; supplies the drop-in T-nuts) | 4 | $15.99 |
- The ViperX 300 6DOF and WidowX 250 6DOF links in the tutorial BOM now redirect to Trossen's /ai page, and Trossen's ViperX 300 S and WidowX 250 S pages are marked discontinued. Trossen now sells ALOHA as kits (Stationary, Mobile, Solo) built on newer hardware; this package describes the original ALOHA only.
- USD prices are the tutorial's 2023 figures. The listed total ($19,529.03) does not equal the sum of the line items; the robots are about $18,000 of it.
- The replacement power supply, DC cables, spade connectors and 10 ft USB cables have links but no prices; the fork spade connector quantity is not stated. The printer is only '~$300'.
- All non-robot vendor links are Amazon US short links (a.co); there are no EU/CN/IN sources upstream.
- OS guidance conflicts: the README lists Ubuntu 18.04/20.04 with ROS 1 Noetic as tested, while the tutorial's Codebase section says Ubuntu 22.04 with ROS 2 Humble. The repo's launch files and scripts are ROS 1.
- The README's arm.py patch (T_sb = None) edits Interbotix toolbox code and must be redone after Interbotix updates.
- Print settings give no layer height or exact wall counts; those are in images in the printing doc. STLs live in a Google Drive folder, not the repo. The repo's aloha2/ folder holds ALOHA 2 parts (wrist cam mount, gravity compensator clips, D405 mounts, workcell) that are out of scope here.
- No real-robot policies are published. The Hugging Face ACT checkpoints are trained in simulation.
- Arms collapse when torque is turned off (no brakes); support them when using Dynamixel Wizard.
- Robot hardware is sold by Trossen under its own terms; the aloha and act code is MIT.
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
Aero Hand Open →Chestnut Robotics (formerly TetherIA) · hand · index 5.5Easiest buildable hand, the next class up from arm. Adds tendon and linkage transmissions.
NoteOriginal repo last pushed Apr 2024; follow-ons (ALOHA 2, commercial kits) exist. Hardware assembly guide is a Google Doc. MIT covers the aloha and act code only; the hardware (Trossen arms) is sold under Trossen's terms and the printed parts have no stated license, so hw is left undeclared.
Sources
- [1]ALOHA repo (MIT)checked 2026-09-24
- [2]Project sitechecked 2026-09-24
- [3]MuJoCo Menagerie alohachecked 2026-09-24
- [4]Trossen Robotics ALOHA kitschecked 2026-09-25
- [5]Trossen ViperX 300 page (marked discontinued)checked 2026-09-25
- [6]LeRobot ACT ALOHA checkpoint (trained in sim)checked 2026-09-25