ArmThe Robot Studio / Hugging Face2025FR
SO-101 (SO-ARM101)
Low-cost 3D-printable 6-DOF leader/follower arm pair built for Hugging Face's LeRobot framework; successor to the SO-100 with improved wiring and easier assembly.
Difficulty index
3.7/13| Class | arm | +2 |
|---|---|---|
| Cost | $230 BOM | +0.4 |
| DOF | 6 DOF | +0.6 |
| Parts | 50 parts | +0.7 |
Specimen photographs
4 items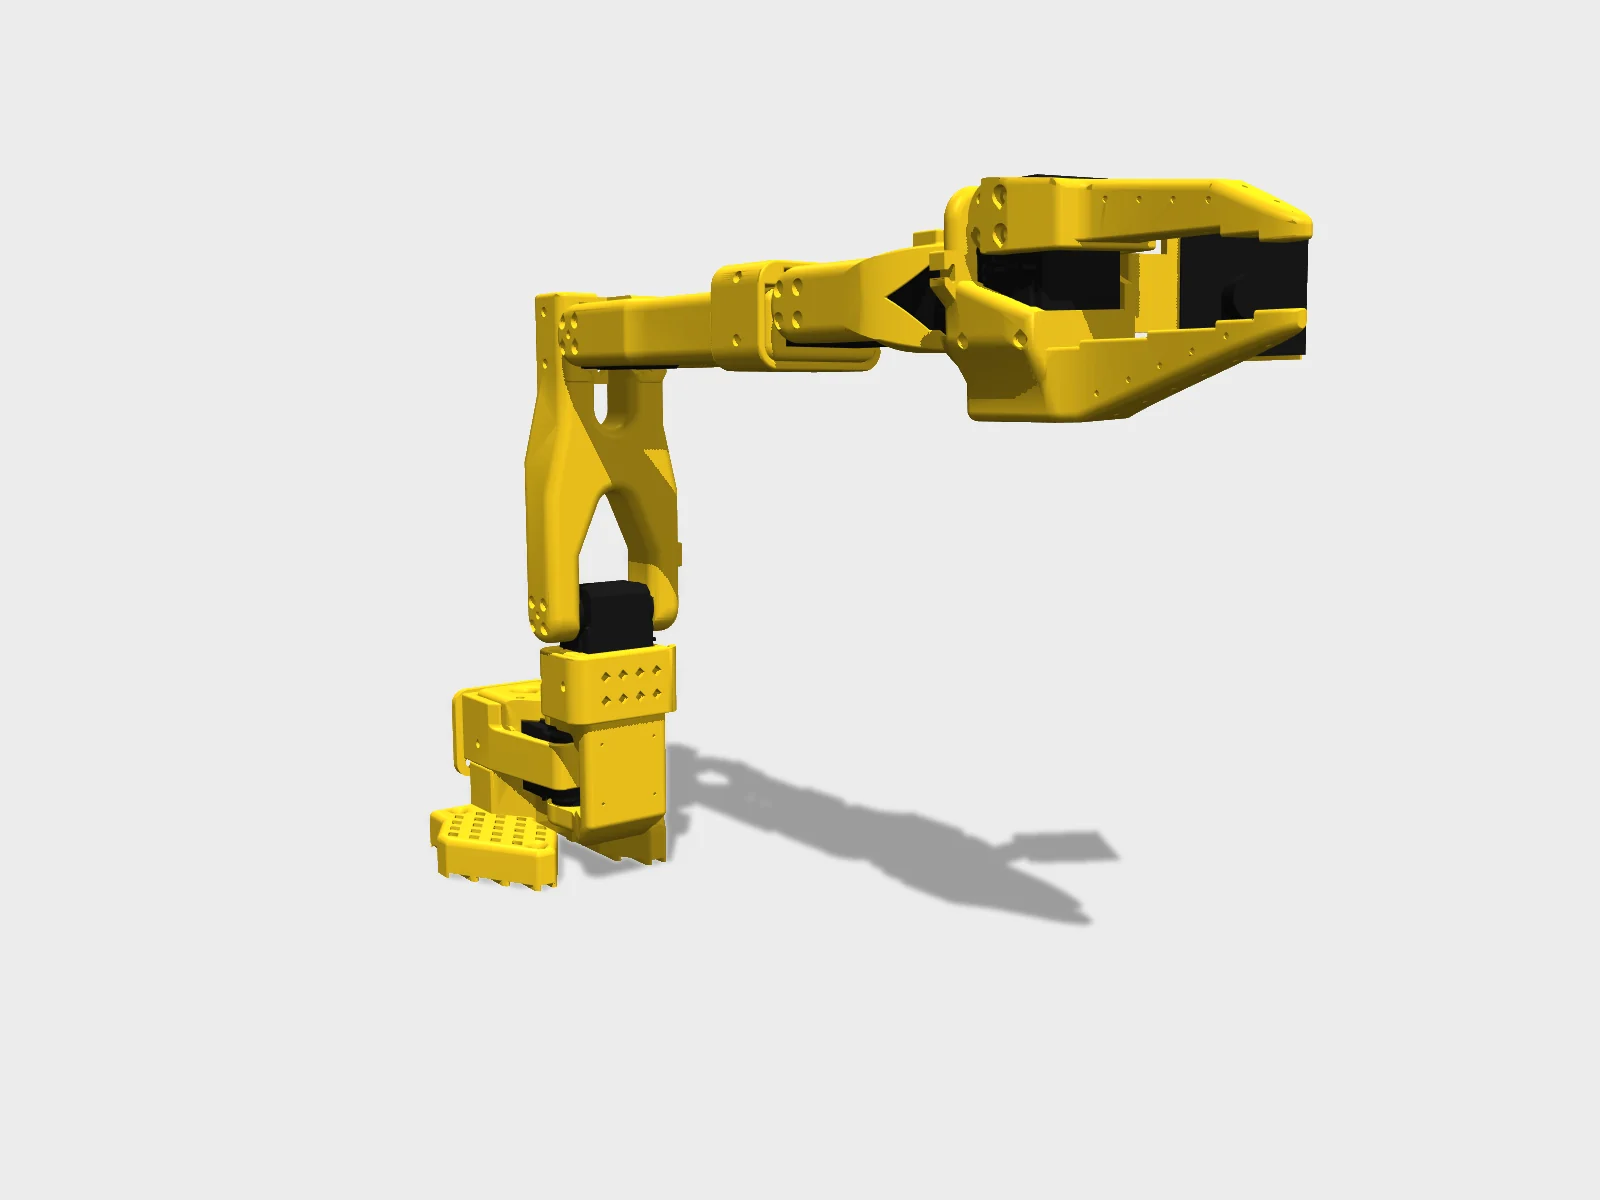
Studio render of the published MJCF, the model's zero pose. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/robotstudio_so101 (Apache-2.0) · Hyperspawn render · source 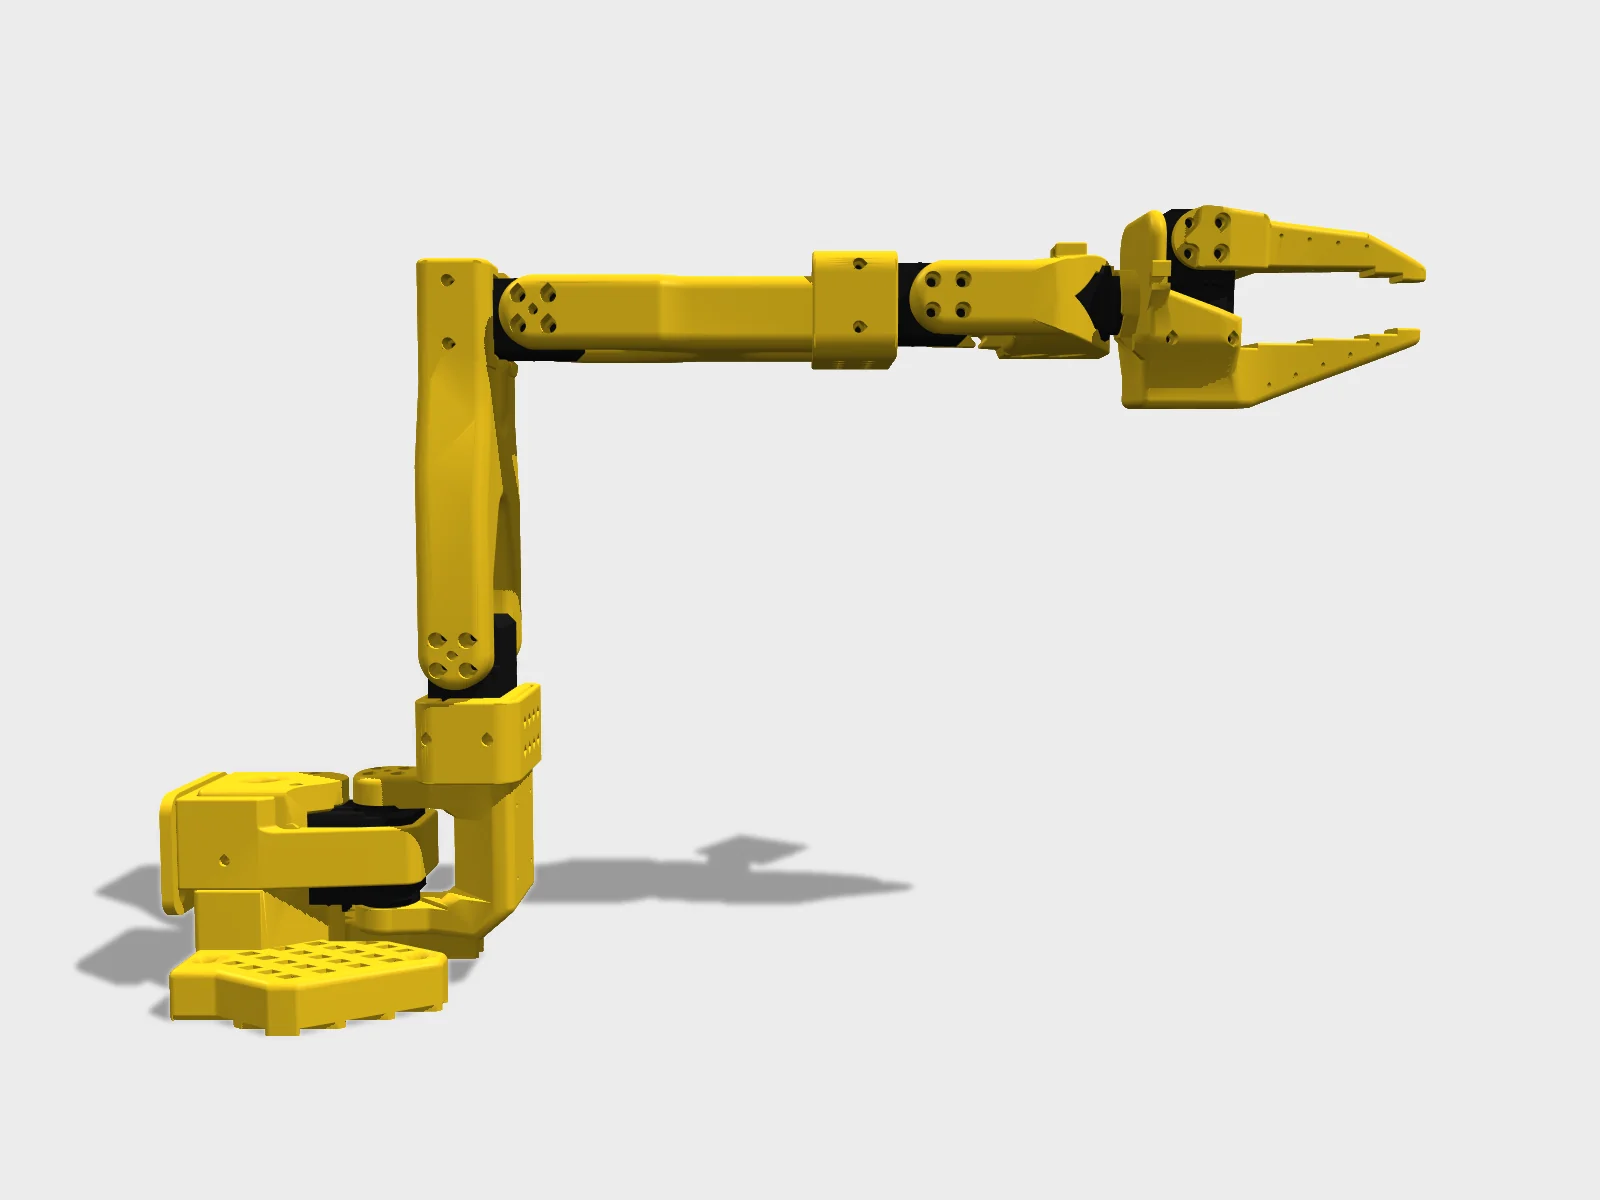
Side view of the same MJCF render, the model's zero pose.Rendered by Hyperspawn from mujoco_menagerie/robotstudio_so101 (Apache-2.0) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/robotstudio_so101 (Apache-2.0) · Hyperspawn render · source 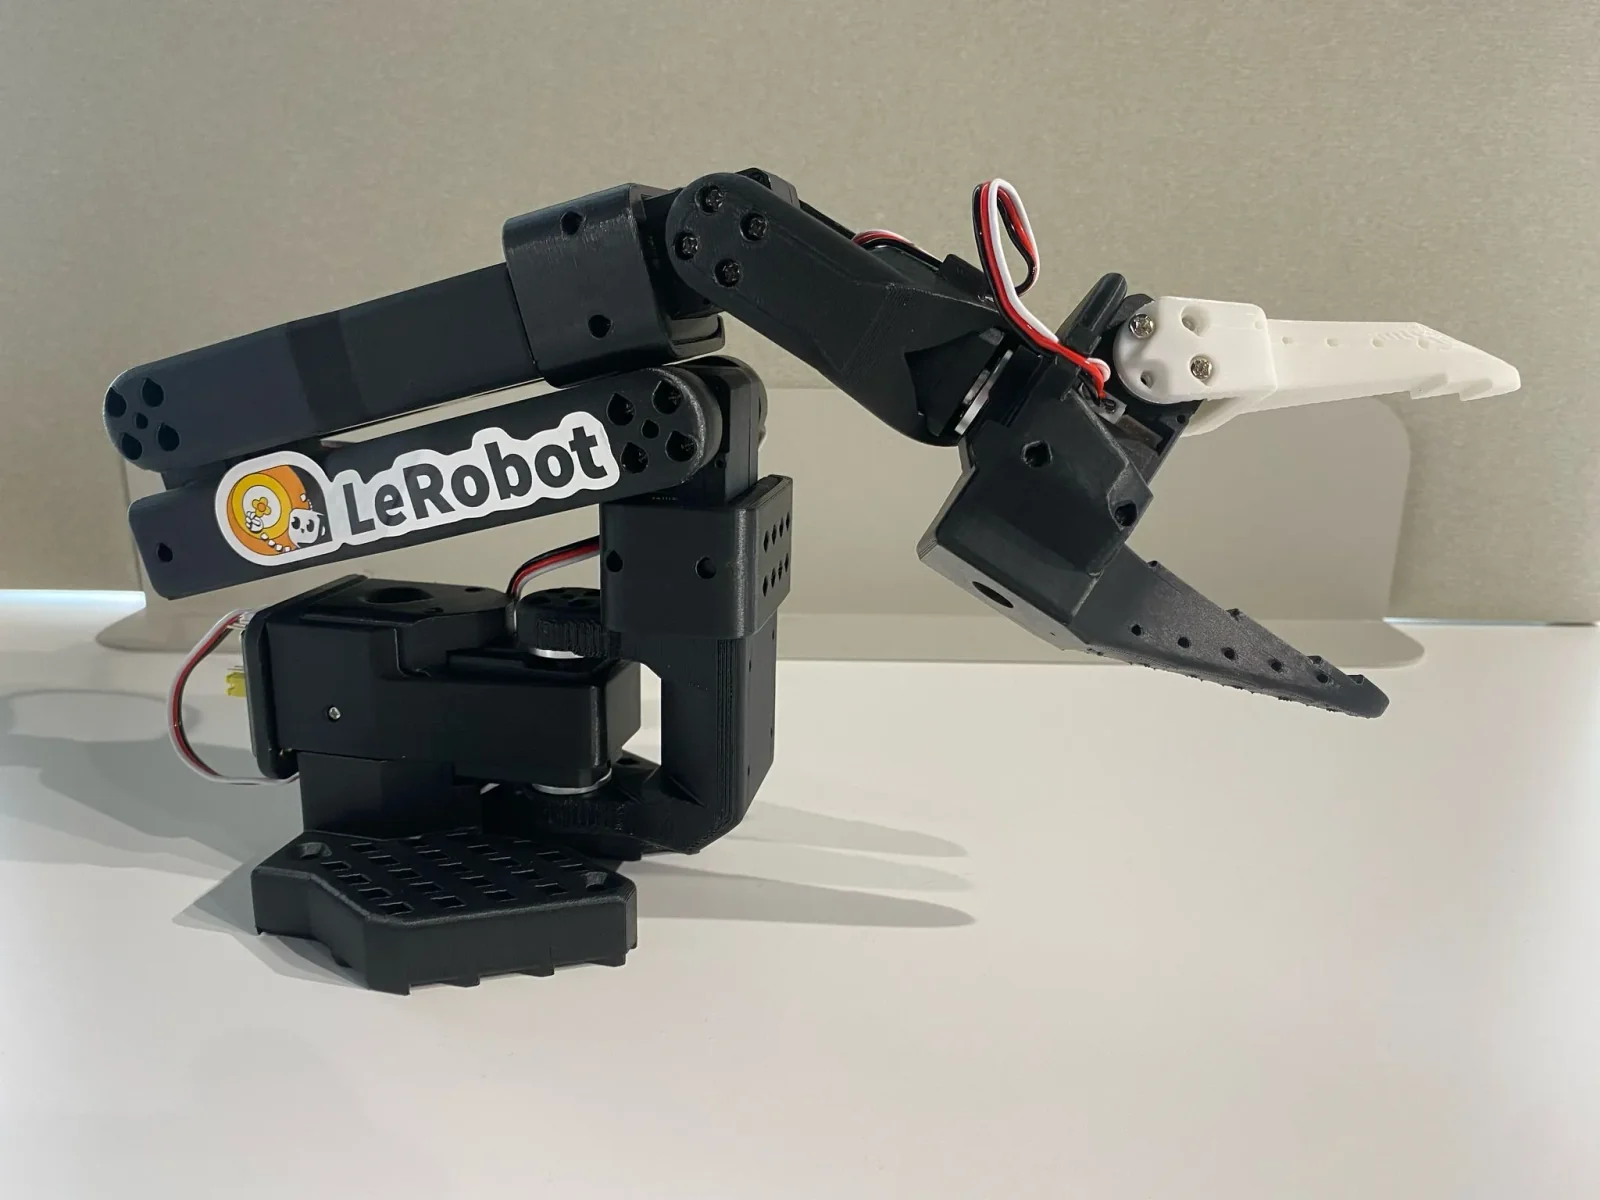
From the SO-ARM100 repo media folder.The Robot Studio (SO-ARM100) · Apache-2.0 · source

Spec card
5/13 known- Degrees of freedom
- 6
- Price
- $220 · Seeed motor kit $220 (Standard) / $240 (Pro) for a leader+follower pair; printed parts ~$35 extra; DIY from ~$130
- BOM total
- $230 · 8/10 lines priced
- Part count
- 50
- Actuators
- Feetech STS3215 serial bus servos (7.4 V or 12 V follower options)
Not in the registry: height, mass, payload, speed, runtime, battery, compute, sensors. Left blank rather than guessed.
What you learn building it
- +Forward and inverse kinematics
- +Joint calibration and homing
- +Trajectory planning
- +Teleoperation and collecting demonstrations for learning
- +FDM 3D printing: 29 parts
- +Tools used: FDM printer, 220x220 mm bed or larger, PLA+ filament, FDM printer, Slicer (Bambu Studio, PrusaSlicer or Cura), Putty knife, Small flat screwdriver, Linux, macOS or Windows computer, conda (miniforge) or uv +5
- +21 assembly steps across 9 subassemblies
- +Flashing firmware for Feetech STS3215 servo (EEPROM: ID 1-6 and bus baudrate, written by lerobot-setup-motors), Waveshare / Seeed serial bus servo driver board (USB serial bridge, no user firmware)
- +Testing in simulation (URDF/MJCF) before touching hardware
- +Running published learned policies
Openness
- publicCAD
- publicBOM
- publicFirmware
- publicSim model
- publicSoftware
- publicPolicies
Score 100/100 computed from what is public: CAD 25, BOM 20, sim 20, firmware 15, software 10, policies 10. Hardware license: Apache-2.0. Software license: Apache-2.0.
Repos & models
Build it
Has an ORP build package.- BOM total
- $230
- Lines priced
- 8/10
- Parts
- 50
- Steps
- 21
- Version
- 0.1.0
2 lines have no price yet, so the real total is higher.
Largest BOM lines
| Part | Qty | Unit |
|---|---|---|
| Feetech STS3215 servo, 7.4 V, 1/345 gear (C001): all 6 follower joints + leader joint 2 (shoulder lift)STS3215 (C001) | 7 | $13.89 |
| Feetech STS3215 servo, 7.4 V, 1/147 gear (C046): leader joints 4 (wrist flex), 5 (wrist roll), 6 (gripper)STS3215 (C046) | 3 | $13.89 |
| Feetech STS3215 servo, 7.4 V, 1/191 gear (C044): leader joints 1 (shoulder pan) and 3 (elbow flex)STS3215 (C044) | 2 | $13.89 |
| Motor control board: Waveshare serial bus servo driver (USB-C), one per arm | 2 | $10.6 |
| DC power supply, 5 V, 5.5x2.1 mm barrel (one per arm, for the 7.4 V servos) | 2 | $10 |
| Table clamp, 4 pcs (holds both arm bases to the table edge) | 1 | $9 |
| USB-C cable, 2-pack (board to computer) | 1 | $7 |
| Precision screwdriver set with Phillips #0 and #1 | 1 | $6 |
- BOM USD unit prices are the upstream README figures (two-arm total $229.88, €226.3, ¥1343.16, ¥44,530) and exclude printed parts and cameras. Alibaba and Amazon listings change often.
- The follower comes in two servo options: 7.4 V STS3215 (16.5 kg·cm stall at 6 V, less on the 5 V supply) or 12 V STS3215 (30 kg·cm), which also needs a 12 V 5 A+ supply. The SO-101 leader is always 7.4 V. Upstream found 7.4 V sufficient.
- Leader gear ratios are easy to mix up. C001 (1/345) is also the follower part; the leader needs 2x C044 (1/191) on joints 1 and 3 and 3x C046 (1/147) on joints 4-6. Upstream lists no CN (TaoBao) link for C044 or C046.
- The upstream BOM has no fastener line. Assembly uses M2x6 and M3x6 screws, and the optional mount guides refer to the M2 screws 'that came with your Feetech servos'. Check your servos include horn and case screws before ordering.
- Cameras are not in the core BOM, but you need at least one to record datasets or run vision policies. The camera lines here come from the optional mount guides and are marked optional.
- Japanese vendor links (Akizuki Denshi, Amazon.co.jp) are shown as region GLOBAL because the registry has no JP region.
- Kits exist (RobotEd CH, Robonine, PartaBot US, ForgeMotion Labs US, Seeed Studio, WowRobo, RoboSEasy KR, NeoBot CN, Autodiscovery EU), sold as frame, electronics, complete or assembled kits. See the README 'Kits' list; this package covers the DIY path.
- Hub policies: flux-3-action-so101 is non-commercial by default (FLUX Kommunity License). MolmoAct2 SO100_101 states no license. smolvla_base is a base model that must be fine-tuned. None of them report success rates on your setup, so each needs matching camera names and a calibrated arm.
- The repo's Software/WEBUI_CALIBRATION.md describes a WebUI calibration (`python pi_servo_studio.py` / `lerobot-calibrate --webui`) that is in neither the SO-ARM100 repo nor lerobot 0.6.2. Use the standard lerobot-calibrate flow.
Simulate
Load it in the browser simulator and train a policy before building.
Open on humanoidrobots.training ↗Next rung
Aero Hand Open →Chestnut Robotics (formerly TetherIA) · hand · index 5.5Easiest buildable hand, the next class up from arm. Adds tendon and linkage transmissions.
NoteReference arm of the LeRobot ecosystem; many community-trained policies for it are on the Hugging Face Hub. Repo very active (pushed Sep 2026). Maker city not public on GitHub (country FR only).
Sources
- [1]GitHub repo (Apache-2.0, BOM)checked 2026-09-24
- [2]Hackster: SO-101 launchchecked 2026-09-24
- [3]CNX Software: SO-ARM101 kit pricingchecked 2026-09-24
- [4]LeRobot SO-101 docschecked 2026-09-25